
技术资料
tf02-pro-w 用户手册
TF02-Pro-W-485
TF02-Pro-W-485
User Manual
Benewake (Beijing) Co., Ltd
PREFACE
Dear users: Thank you for choosing Benewake products. In the purpose of offering better operation experience to you, we hereby write this manual for an easier and simpler operation of our product, hoping to better solve the common problems you may meet. This user manual contains relevant information on product introduction, usage and maintenance of TF02-Pro-W-485, covers the product operation introduction and common problem solutions. Please read this manual carefully before using the product. Remember the precautions to avoid hazards, and please follow the described steps in the manual when using it.
If you have any problems in the process of using, you are welcome to contact Benewake at any time for help.
Contact Details Official website: https://ai.benewake.com/zh/products/tf02-pro-w/ TEL:+86-10-57456983 Technical questions,please contact: support@benewake.com Consult sale information or request brochure,please contact: bw@benewake.com
Headquarters Address Benewake (Beijing) Co., Ltd. 3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China
Copyright Statement This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer As our products are constantly improving and updating, the specifications of TF02-Pro-W-485 are subject to change. Please refer to the official website for latest version.
CONTENTS
1 OVERVIEW ...................................................................................................................... 1 1.1 Technical Specification .............................................................................................1 1.2 Maintenance and Cleaning .......................................................................................2 1.3 Appearance and Structure ........................................................................................2 1.4 Storage ................................................................................................................... 4 2 INTERFACE ......................................................................................................................5 2.1 Description About Wiring Sequence .......................................................................... 5 2.2 Electrical Characteristics ...........................................................................................5 3 WIPER WORKING ............................................................................................................. 6 4 COMMUNICATION PROTOCOL ...........................................................................................7 4.1 RS-485 Communication Interface ..............................................................................7 4.2 Modbus Protocol ......................................................................................................7
4.2.1 Description about frame format ................................................................7 4.2.2 Function Code .......................................................................................... 8 4.2.3 Register Address ...................................................................................... 8 4.3 Parameter Configuration ..........................................................................................9 4.4 Configuration Example ...........................................................................................11
OVERVIEW
1 OVERVIEW
TF02-Pro-W-485 is a single-point ranging LiDAR based on upgraded TF02-Pro-W using ToF (Time of Flight) principle. It has been optimized in communication interface, input voltage and reverse voltage protection, adapted to the needs of industrial scenarios.
1.1 Technical Specification
Table 1- 1 Technical specification of TF02-Pro-W-485 Type Parameters Value
90% reflectivity, 0Klux 0.1m~25m
Operating 10% reflectivity, 0Klux 0.1m~12m range 90% reflectivity, 100Klux 0.1m~25m
10% reflectivity, 100Klux 0.1m~12m Accuracy ① ±6cm(0.1m~6m),
Product ±1%(6m~25m) performance Distance resolution ① 1cm
Frame rate ② 1Hz~1000Hz
( adjustable, default 100Hz)
Repeatability ① 1σ: <2cm
(0.1m~25m@90% reflectivity )
Ambient light immunity 100Klux Enclosure rating IP5X
| Parameter | Value |
|---|---|
| Photobiological safety | Class1 (IEC60825) |
| Optical Central wavelength | 850nm |
| parameters | Light source VCSEL |
FoV ③ 3° Supply voltage DC 7V~30V
Electrical Average current ≤200mA@12V parameters Power consumption ≤4.8W
Peak current 400mA@12V Dimension 85mm×59mm×43mm (L×H×W)
Others Housing PC/ABS
Operating temperature -20℃~60℃
OVERVIEW
Storage temperature -30℃~80℃ Weight 92g (with cables) Cable length 120cm
Note 1 The detection range is measured with the standard white board (90% reflectivity). 2 The frame rate can be adjusted. The default value is 100Hz and the maximum value is 1000Hz, customized frame rate should be calculated by the formula: 2000/n (n is an integer with ≥ 2). 3 The angle is a theoretical value, the actual angle value has some deviation.
1.2 Maintenance and Cleaning
Before switching on, please check if the exposed window mirror is clean, and clean it promptly if it is dirty. After using the device, check the optics. If they are contaminated, please clean it promptly. The optics should be cleaned regularly if the device be operated in a severe environment for a long time. Before regular cleaning, please disconnect the power. Using a soft cloth to gently wipe the window in the same direction when the device is not operating, to avoid repeated wiping and damage to the window mirror. Do not remove the dust-removal wiper, which may cause equipment failure. If the dust-removal wiper is abnormal, please contact bw@benewake.com. When the steering shaft is blocked by dust for a long time, the steering shaft may be damaged due to the increased resistance. Please clean the steering shaft regularly. If you require deep cleaning of internal optics, please contact bw@benewake.com to offer professional advice.
1.3 Appearance and Structure
The appearance and dimensions of TF02-Pro-W-485 are shown in Figure 1- 1 and Figure 1- 2.
OVERVIEW
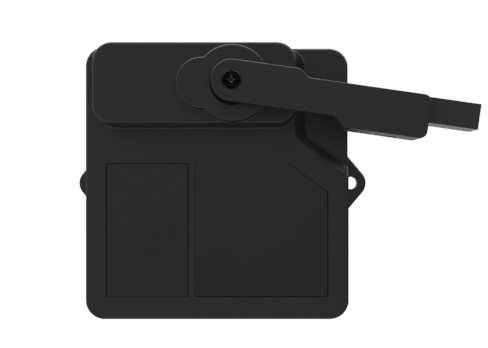
Figure 1- 1 Appearance of TF02-Pro-W-485
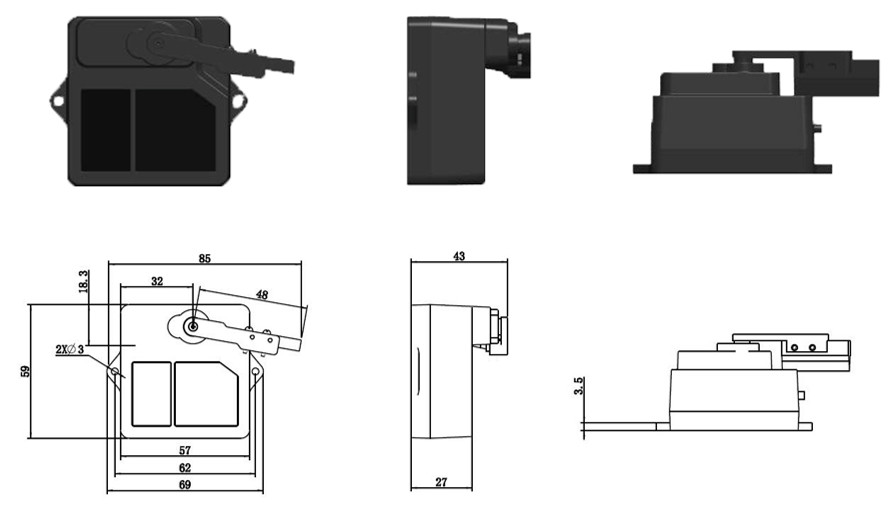
Figure 1- 2 Dimension of TF02-Pro-W-485 (unit: mm)
TF02-Pro-W-485 is recommended to use M2.5 round Phillips screws for installation. Please remove the protective film of the optical lens before use. The lens of front panel of LiDAR cannot be covered. Please keep it clean. The surface of optical lens is the ranging zero of LiDAR. The detection angle of TF02-Pro-W-485 is 3°. At different distances, the size of light spot, namely the edge length of the detection range, is different, as shown in Figure 1- 3. Side length of the detection range at different distances (the detection range is a square), as shown in Table 1- 2.
OVERVIEW
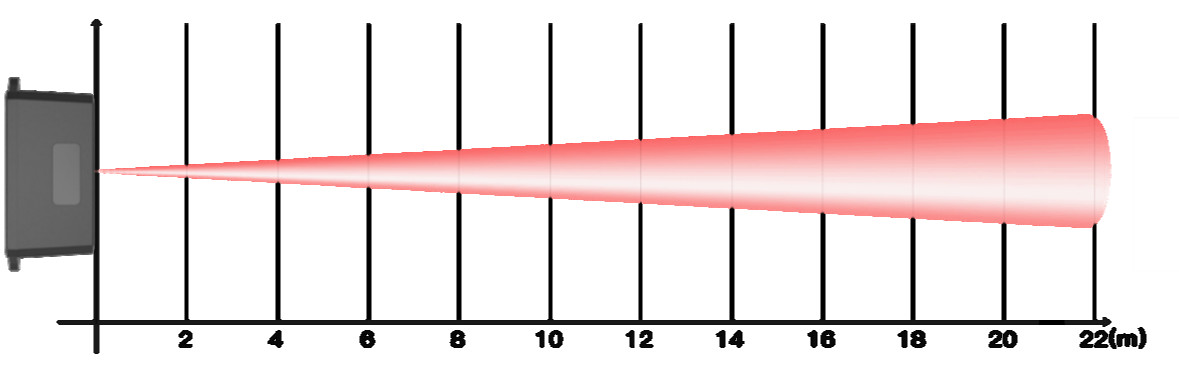
Figure 1- 3 Light spot size at different distances
Table 1- 2 Spot Size at Different Distances Distance(m) 1 2 3 4 5 6 7 8 9 10 15 20 22 Spot size(cm) 5 10 16 21 26 31 37 42 47 52 79 105 115
Note The side length of target object generally should be larger than size of the TF02-Pro-W-485 light spot; if the side length of the detected object is smaller than size of light spot, the output (Distance) from TF02-Pro-W-485 will be a value between the actual distance values of the two objects.
1.4 Storage
Device should be stored at -30°C to 80°C with a relative humidity ≤ 60% and ventilation free from corrosive gases. Before storage, please make sure that all connections are disconnected or dust covers are inserted or covered to ensure cleanliness. If storage time is over three months, please carry out a working test before using, to ensure that the device can be used in normal condition. For ensuring the product performance, do not open the product shell or remove the IR-pass filter.
INTERFACE
2 INTERFACE
2.1 Description About Wiring Sequence
The external tail cable of TF02-Pro-W-485 has no connector by default, the wiring sequence is shown in Table 2- 1. Table 2- 1 The function description of each wire
| Parameter | Value |
|---|---|
| Wiring color | Function Comment |
| Red | VCC Power supply |
| Black | GND Ground |
| White | RS-485-B DATA- |
| Green | RS-485-A DATA+ |
2.2 Electrical Characteristics
TF02-Pro-W-485 has over-voltage and reverse polarity protection, but do not connect to power rails higher than 36V, reverse polarity protection voltage is -30V. The electrical characteristics are shown in Table 2- 2. Table 2- 2 Main electrical parameters of TF02-Pro-W-485
Parameter Value Supply voltage DC 7V~30V Average current ≤200mA@12V Peak current 400mA@12V
Average power consumption ≤4.8W Communication level RS-485
WIPER WORKING
3 WIPER WORKING
The dust-removal wiper works in a fixed cycle, having a dust-removal operation every 4 hours in the default working mode. Each dust-removal operation is driven by the LiDAR servo, the wiper moves backwards and forwards for one time. And TF02-Pro-W-485 will also perform dust-removal operation once after each power-on. In addition, customer can control the LiDAR immediately by sending command for dust-removal, and modify the wiper swing times and save the settings. During the dust removal operation, the LiDAR does not measure and output data. The wiper stops at position A when it does not work, and moves from position A to position B during operation, then returns to position A, the initial and termination positions are shown in Figure 3- 1.
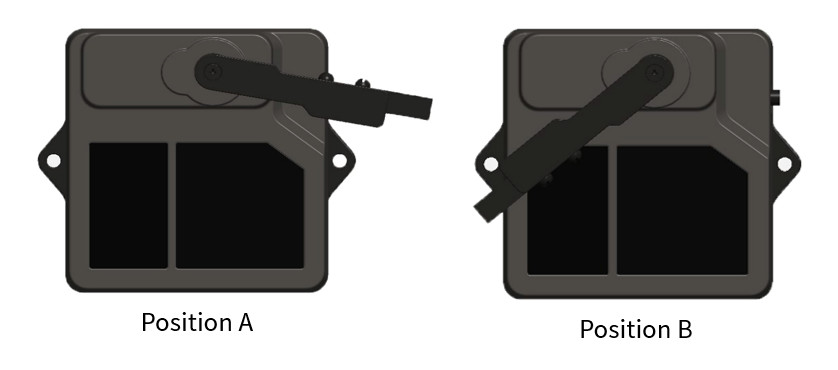
Figure 3- 1 The initial and termination positions of the wiper movement Note It is recommended that the dust-removal interval should be kept greater than 30 minutes,when servo is in high temperature environments (ambient temperature > 40 ℃).
COMMUNICATION PROTOCOL
4 COMMUNICATION PROTOCOL
4.1 RS-485 Communication Interface
TF02-Pro-W-485 uses RS-485 communication standard with 2-wire interface, the
communication protocol parameters are shown in Table 4- 1. The default baud rate is
115200, the default slave ID is 0x01. Table 4- 1 TF02-Pro-W-485 RS-485 communication protocol
Communication interface RS-485 Default baud rate 115200
Data bit 8 Stop bit 1 Parity check None
Warning TF02-Pro-W-485 supports 9600, 14400, 19200, 38400, 43000, 57600, 76800, 115200 (default), 128000, 230400, 256000, 460800, 921600, 1382400 baud rates. It is not recommended to use the baud rate above 115200.
4.2 Modbus Protocol
4.2.1 Description about frame format
When TF02-Pro-W-485 Modbus protocol is enabled, the Modbus reading distance command format is shown in Table 4- 2. Table 4- 2 The Modbus reading distance command format Address Function Register Register CRC_Low CRC_High field code address number 01 03 00 00 00 01 xx xx The data frame returned by TF02-Pro-W-485 is as follows: Table 4- 3 The data frame format Address Function Data Dist_High Dist_Low CRC_Low CRC_High field code length 01 03 02 XX XX xx xx
COMMUNICATION PROTOCOL
4.2.2 Function Code
The function code of TF02-Pro-W-485 is shown in Table 4- 4. Table 4- 4 The function code of TF02-Pro-W-485
Function code Description 03 Read register 06 Write register
4.2.3 Register Address
All register addresses are hexadecimal and register values are 16 bits; After setting parameter, save settings and restart LiDAR to take effect. 4.2.3.1 Register Address for Reading Function Code
Table 4- 5 Register address list using function code: 0x03(read only) Register address Definition Description 00 00 Dist Distance, unit: cm 00 01 Strength Signal strength 00 03 High 16bit of 2 high-order bits of timestamp represent
timestamp relative time of LiDAR start up, unit: ms
00 04 Low 16bit of 2 low-order bits of timestamp represent
timestamp relative time of LiDAR start up, unit: ms
High 16bit of
00 06 software 00 + major version number
version Low 16bit of Minor version number + revised version
00 07 software number
version
4.2.3.2 Register Address for Writing Function Code
Table 4- 6 Register address list using function code: 0x06(write only) Register address Definition Description 00 80 Save settings Write any value to save settings
Power Register value:
00 81 off/restart 0-Power off (unavailable currently);
1-Restart
00 82 Disable Modbus Register value:
COMMUNICATION PROTOCOL
1-Disable Modbus;
Others-Error reply
00 83 Baud rate High Set baud rate. Restart to take effect 00 84 Baud rate Low Set baud rate. Restart to take effect 00 85 Slave ID Set slave ID. Restart to take effect (default
0x01)
00 86 FPS Set frame rate. Restart to take effect (default
100Hz)
Set working mode. Restart to take effect after saving settings. Register value:
00 87 Working mode 0- Continuously detection mode(default)
1-Trigger mode
Others-Error reply
Set low-power consumption mode,Restart to
Low-power take effect after saving settings. Register
00 88 consumption value:
mode 0-Disable(default)
>0 and≤10-Enable (the value is inside sampling frequency.)
00 89 Restore defaults Write any value. Restart to take effect after
saving settings.
00 8A Start the wiper Write any value. Start the wiper at any time.
Modify Unit: minutes (default 240 minutes). Take
00 8C dust-removal effect immediately.
cycle
00 8D Modify number The number should between 1 and 10
of wiper swings (default once). Take effect immediately.
4.3 Parameter Configuration
Table 4- 7 TF02-Pro-W-485 general parameter configuration under serial link mode Function Command Response Description Enable Modbus 5A 05 15 01 75 5A 05 15 01 75 Save settings and restart to take
effect.
Save setting 5A 04 11 6F 5A 05 11 00 70 Table 4- 8 TF02-Pro-W-485 general parameter configuration with Modbus instructions Function Command Response Description
COMMUNICATION PROTOCOL
DH: 8 high-order bits of distance
Read distance 01 03 00 00 00 01 03 02 DH DL: 8 low-order bits of distance
01 84 0A DL CL CH CL: 8 low-order bits of CRC
CH: 8 high-order bits of CRC
DH: 8 high-order bits of distance
DL: 8 low-order bits of distance
SH: 8 high-order bits of signal
Read distance 01 03 00 00 00 01 03 04 DH strength and strength 02 C4 0B DL SH SL CL CH SL: 8 low-order bits of signal
strength
CL: 8 low-order bits of CRC
CH: 8 high-order bits of CRC
| Parameter | Value |
|---|---|
| Read 01 03 00 06 00 | 01 03 04 00 |
| firmware 02 24 0A | VM VS VC CL The software version is VM.VS.VC |
| version | CH |
01 06 00 83 01 06 00 83 BH1, secondary high, secondary low and BH2, BL1, BL2 are high,
Set baud rate BH1 BH2 CL CH BH1 BH2 CL CH low bytes of baud rate. E.g., set baud
01 06 00 84 01 06 00 84 rate to 9600 (0x00002580) BH1=00 BH2=00 CL=78 CH=22
| Parameter | Value |
|---|---|
| BL1 BL2 CL CH | BL1 BL2 CL CH BL1=25 BL2=80 CL=D2 CH=D3 |
| 01 06 00 85 IH | 01 06 00 85 IH IH, IL are high and low bytes of ID. |
| Set slave ID IL CL CH | IL CL CH For example, set ID to 2,IH=00 IL=02 |
CL=19 CH=E2
FH, FL are high and low bytes of
Set frame rate 01 06 00 86 FH 01 06 00 86 FH frame rate. E.g., Set frame rate to 100
FL CL CH FL CL CH (0x0064),
FH=00 FL=64 CL=69 CH=C8
| Parameter | Value |
|---|---|
| Set | LH, LL are high and low bytes of low power sampling rate. |
| low-power 01 06 00 88 LH | 01 06 00 88 LH For example, set it to 5HZ low-power |
| consumption LL CL CH | LL CL CH consumption mode, LH=00 LL=05 |
| mode | CL=C9 CH=E3 |
| Save settings 01 06 00 80 00 | 01 06 00 80 00 Save settings and restart LiDAR to |
00 88 22 00 88 22 take effect
| Parameter | Value |
|---|---|
| Disable 01 06 00 82 00 | 01 06 00 82 00 Save settings and restart LiDAR to |
| Modbus 01 E8 22 | 01 E8 22 take effect |
| Start the 01 06 00 8A 00 | 01 06 00 8A 00 Start the wiper at any time |
| wiper 00 A8 20 | 00 A8 20 |
| Modify dust 01 06 00 8C PH | 01 06 00 8C PH PH, PL are high and low bytes of cycle. |
COMMUNICATION PROTOCOL
removal cycle PL CL CH PL CL CH E.g., making wiper works every 240
minutes (0x00F0), PH=00 PL=F0 CL=48
CH=65
| Parameter | Value |
|---|---|
| Modify the | WH, WL are high and low bytes of number of round trips. The number |
| number of 01 06 00 8D | 01 06 00 8D should between 1 and 10. E.g., twice |
| wiper round WH WL CL CH | WH WL CL CH each time |
| trips | WH=00 WL=02 CL=98 CH=20 |
Warning TF02-Pro-W-485 Only supports RTU mode to communicate in serial link.
4.4 Configuration Example
1) Under RS-485 serial link mode, enable Modbus protocol: 5A 05 15 01 75 // Enable Modbus protocol 5A 04 11 6F // Save setting Restart and enter Modbus mode.
2) Under Modbus mode, disable Modbus Protocol: 01 06 00 82 00 01 E8 22 // Default address 01, disable Modbus 01 06 00 80 00 00 88 22 // Default address 01, save setting Restart and exit Modbus.