
技术资料
tf02-i 用户手册
TF02-i User Manual
TF02-i User Manual
Benewake (Beijing) Co., Ltd
PREFACE
Dear users: Thank you for choosing Benewake products. For the purpose of offering better operation experience to you, we hereby write this manual for an easier and simpler operation of our product, hoping to better solve the common problems you may meet. This user manual contains the relevant information on product introduction, usage and maintenance of TF02-i, covers the product operation introduction and common problem solutions. Please read this manual carefully before using the product. Remember the precautions to avoid hazards, and please follow the described steps in the manual when using it.
If you have any problems in the process of usage, you are welcome to contact Benewake at any time for help.
Contact Details Official website: https://ai.benewake.com/zh/products/tf02-i/ TEL:+86-10-57456983 Technical questions,please contact: support@benewake.com Consult sale information or request brochure,please contact: bw@benewake.com
Headquarters Address Benewake (Beijing) Co., Ltd. 3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China
Copyright Statement This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer As our products are constantly improving and updating, the specifications of TF02-i are subject to change. Please refer to the official website for latest version.
CONTENTS
1 OVERVIEW........................................................................................................................................... 1
| Parameter | Value |
|---|---|
| 1.1 Technical Specification | ...........................................................................................................1 |
| 1.2 Maintenance and Cleaning | .................................................................................................... 2 |
| 1.3 Appearance and Structure | ..................................................................................................... 2 |
1.4 Storage.....................................................................................................................................3 1.5 Application.............................................................................................................................. 4 2 INTERFACE...........................................................................................................................................5
| Parameter | Value |
|---|---|
| 2.1 Description About Wiring Sequence | ..................................................................................... 5 |
| 2.2 Electrical Characteristics | ........................................................................................................ 5 |
| 3 COMMUNICATION PROTOCOL | ............................................................................................................6 |
| 3.1 RS-485 Communication Protocol | ...........................................................................................6 |
| 3.1.1 Communication protocol | .............................................................................................6 |
| 3.1.2 Parameter configuration description of Modbus protocol | .......................................6 |
| 3.1.3 Parameter configuration | .............................................................................................8 |
| 3.2 CAN Communication Protocol | ..............................................................................................10 |
| 3.2.1 Communication Protocol | ...........................................................................................10 |
| 3.2.2 CAN Communication Data Frame | ............................................................................. 11 |
| 3.2.3 CAN Bus Network | ....................................................................................................... 11 |
| 3.2.4 Parameter Configuration of CAN Communication | .................................................. 12 |
| 3.2.5 Other Parameter Configuration | ................................................................................ 12 |
OVERVIEW
1 OVERVIEW
TF02-i is a single-point ranging LiDAR upgraded based on TF02-Pro. It has been optimized and upgraded in terms of communication interface, input voltage, etc., to meet the needs of various industrial scenarios. The product is based on the principle of ToF (time of flight) and has stable, accurate and highly sensitive measurement performance.
1.1 Technical Specification
Table 1- 1 Technical Specification of TF02-i Type Parameters Values
90% reflectivity, 0Klux 0.1m~40m
Operating 10% reflectivity, 0Klux 0.1m~13.5m range 90% reflectivity, 100Klux 0.1m~40m
10% reflectivity, 100Klux 0.1m~13.5m
Product Accuracy ① ±5cm(0.1m~5m),±1%(5m~40m) performance Distance resolution ① 1cm
Frame rate ② 1Hz~100Hz(adjustable, default100Hz) Repeatability ① 1σ: <2cm(0.1m~35m@90% reflectivity) Ambient light immunity 100Klux Enclosure rating IP65
| Parameter | Value |
|---|---|
| Photobiological safety | Class1 (IEC60825) |
| Optical | Central wavelength 850nm |
| parameters | Light source VCSEL |
FoV ③ 3° Supply voltage DC 7V~30V
Electrical Average current ≤70mA @12V parameters Power consumption ≤0.85W @12V
Peak current 100mA Dimension 69mm×41.5mm×31.5mm (L×H×W) Housing ABS/PC/PMMA
Others Operating temperature -20℃~60℃
Storage temperature -30℃~80℃ Weight 60g (with cables) Cable length 70cm
OVERVIEW
Note 1 The detection is measured with the standard white board (90% reflectivity). 2 The frame rate can be adjusted. The default value is 100Hz and the maximum value is 100Hz, the customized frame rate should be calculated by the formula: 200/n (n is an integer with ≥ 2). 3 The angle is a theoretical value, the actual angle value has some deviation.
1.2 Maintenance and Cleaning
Before switching on, please check if the exposed window mirror is clean, and clean it promptly if it is dirty. After using the device, check the optics. If it is contaminated, please clean it promptly. The optics should be cleaned regularly if the device be operated in a severe environment for a long time. Before regular cleaning, please disconnect the power. Using a soft cloth to gently wipe the window in the same direction when the device is not operating, to avoid repeated wiping and damage to the window mirror. When cleaning the window, do not use alcohol to clean, so as not to damage the window. If you require deep cleaning of internal optics, please contact bw@benewake.com to offer professional advice.
1.3 Appearance and Structure
The appearance and dimensions of TF02-i are shown in Figure 1- 1 and Figure 1- 2:
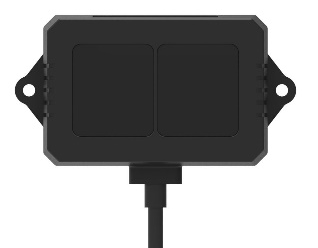
Figure 1- 1 Appearance of TF02-i
OVERVIEW
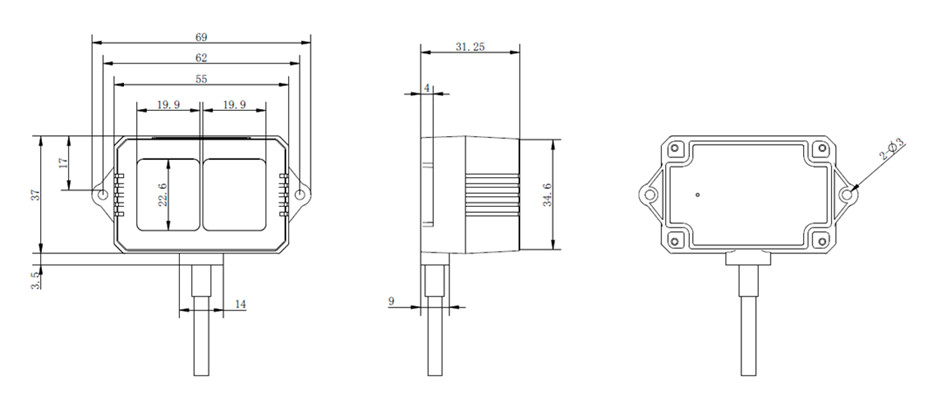
Figure 1- 2 Dimension of TF02-i (Unit: mm)
TF02-i is recommended to use M2.5 round Phillips screws for installation. Please remove the protective film of the optical lens before use. The lens of front panel of LiDAR cannot be covered. Please keep it clean. The surface of optical lens is the ranging zero of LiDAR. The detection angle of TF02-i is 3°. At different distances, the size of light spot, namely the edge length of the detection range, is different. Side length of the detection range at different distances (the detection range is a square), as shown in Table 1- 2. Table 1- 2 Spot Size at Different Distances
Distance(m) 1 2 3 5 7 10 20 30 40 Spot size(cm) 5 10 16 26 37 52 105 156 208
Note The side length of target object generally should be larger than size of the TF02-i light spot; if the side length of the detected object is smaller than size of light spot, the output (Distance) from TF02-i will be a value between the actual distance values of the two objects.
1.4 Storage
Device should be stored at -30°C to 80°C with a relative humidity ≤ 60% and ventilation free from corrosive gases. Before storage, please make sure that all connections are disconnected or dust covers are inserted or covered to ensure cleanliness. If storage time is over three months, please carry out a working test before using, to ensure that the device can be used in normal condition. For ensuring the product performance, do not open the product shell or remove the IR-pass filter.
OVERVIEW
1.5 Application
When using the product, please read the specifications, user manual and the precautions mentioned in the user manual in detail to ensure that the product is used within the rated specifications. The product is designed for use in the following scenarios: Robot Intelligent Transportation Intelligent Device UAV Other Industrial Products If you use the product beyond the above application scope, please carefully evaluate whether the reliability requirements of the product to be applied match this product, or contact Benewake at any time to assist in solving it.
INTERFACE
2 INTERFACE
2.1 Description About Wiring Sequence
Terminal model: MH1.25-7P-W/B, size of single wire is AWG26, diameter of single wire is 0.404mm, cross-sectional area is 0.129mm 2, which show in Table 2- 1.
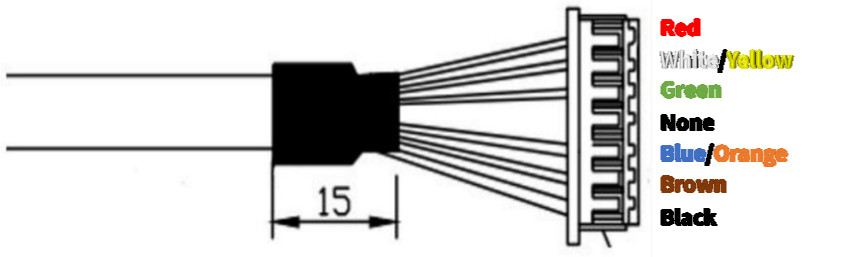
Figure 2- 1 TF02-i external wiring connector and wiring sequence
Table 2- 1 The Function Description of Each Wire Pin Wiring color Function Comment
1 Red VCC Power supply 2 White/Yellow RS485-B/CAN_L RS485-B/CAN bus 3 Green RS485-A/CAN_H RS485-A/CAN bus 4 N/A N/A N/A 5 Blue/Orange UART_RXD UART receive (Debug) 6 Brown UART_TXD UART transmit (Debug) 7 Black GND Ground Warning 1 The hardware of RS-485 and CAN is different; Do not mix UART cable with RS485 or CAN bus, otherwise it will cause damage of MCU. 2 TF02-i with RS-485 interface does not support UART debugging pins.
2.2 Electrical Characteristics
Table 2- 2 Main Electrical Parameters of TF02-i
Parameter Values Supply voltage DC 7V~30V Average current ≤70mA@12V Peak current 100mA
Average power consumption ≤0.85W@12V
COMMUNICATION PROTOCOL
3 COMMUNICATION PROTOCOL
There are two communication interfaces available. The hardware of RS485 and CAN is different. The interface can not be switched by command.
3.1 RS-485 Communication Protocol
3.1.1 Communication protocol
Modbus protocol is the default setting for RS-485 interface. The parameter is shown in Table 3- 1. The default value of baud rate and slave ID is 115200 and 0x01. Table 3- 1 RS-485 Communication protocol of TF02-i
Characteristics Values Communication interface RS-485 Baud rate 115200 Data bit 8 Stop bit 1 Parity None
Note The following baud rates are supported: 9600,14400,19200,38400,43000, 57600 , 768000 , 115200(default) , 128000 , 230400 , 256000. It is not recommended to use a baud rate above 115200 for communication because of communication stability.
3.1.2 Parameter configuration description of Modbus protocol
3.1.2.1 Description of data frame
When Modbus protocol of TF02-i is enabled, the Modbus command format of reading distance is shown in Table 3- 2. Table 3- 2 The command format of reading distance Addr. Function code Register Addr. Register Value CRC_Low CRC_High 01(Default) 03 00 00 00 01 xx xx The response data frame format is shown in Table 3- 3.
COMMUNICATION PROTOCOL
Table 3- 3 The response date frame format Addr. Function code Length Dist_High Dist_Low CRC_Low CRC_High 01(Default) 03 02 XX XX xx xx
3.1.2.2 Function code
The function code of TF02-I is shown in Table 3- 4. Table 3- 4 The function code
Function Code Description 03 Read register 06 Write register
3.1.2.3 Register address list
All register addresses are hexadecimal and register values are 16 bits; After setting parameter, save and restart to take effect. Register address list using function code: 0x03(read only) Table 3- 5 Register address of function code (0x03) Register Definition Description Addr.
| Parameter | Value |
|---|---|
| 00 00 Dist | Distance value, unit: cm |
| 00 01 Strength | Signal strength |
| 00 03 High 16 bits of timestamp | High 2 bytes of time stamp, unit: ms |
| 00 04 Low 16 bits of timestamp | Low 2 bytes of time stamp, unit: ms |
| 00 06 High | 16 bits of firmware 0x00 and main version number |
version
00 07 Low 16 bits of firmware version Sub-version and revised version
number
Register address list using function code: 0x06(write only): Table 3- 6 Register address of function code (0x06) Register Addr. Definition Description 00 80 Save setting Write any value to save settings
Register value:
00 81 Power off/Reboot 0x00: power off (Not currently
supported)
0x01: reboot
00 82 Disable Modbus Register Value:
0x01: Disable Modbus
COMMUNICATION PROTOCOL
| Parameter | Value |
|---|---|
| 00 83 High 16 bits of baud | Set baud rate, save and reboot to take |
| rate | effect |
| 00 84 Low 16 bits of baud rate | Set baud rate, save and reboot to take |
effect
00 85 Slave ID Set slave ID, save and reboot to take
effect (default 0x01)
00 86 Frame rate Set frame rate, save and reboot to take
effect (default 100Hz)
Set working mode, save and reboot to
take effect. Register value:
00 87 Working mode 0x00: continuous detection mode
(default)
0x01: triggering mode
Set low power consumption mode, save
Low power and reboot to take effect. Register value:
00 88 consumption mode 0x00: Disable (default)
0x0N: Enable, N is a positive integer with
≤10,which is sampling frequent of TF02-i
00 89 Restore default Write any value, save and reboot to take
effect
3.1.3 Parameter configuration
Table 3- 7 General command of RS-485 serial communication mode
| Parameter | Value |
|---|---|
| Function Command | Respnse Description |
| Enable 5A 05 15 01 75 | 5A 05 15 01 Save and reboot to take effect |
| Modbus | 75 |
| Strength | The default setting is: |
| threshold and | When strength is below 60, make |
| distance 5A 07 22 XX LL | 5A 07 22 XX distance output 4500cm: |
| under HH SU | LL HH SU XX=60/10=6(DEC)=06(HEX) |
| threshold | 4500(DEC)=1194(HEX) |
LL=94,HH=11
Save setting 5A 04 11 6F 5A 05 11 00
COMMUNICATION PROTOCOL
Table 3- 8 General command of Modbus protocol Function Command Response Description
DH: High 8 bits of distance
Read 01 03 00 00 00 01 03 02 DH DL: Low 8 bits of distance distance 01 84 0A DL CL CH CH: High 8 bits of CRC
CL: Low 8 bits of CRC
| Parameter | Value |
|---|---|
| Read | 01 03 04 DH |
| distance and 01 03 00 00 00 | DL SH SL CL SH: High 8 bits of signal strength |
| signal 02 C4 0B | CH SL: Low 8 bits of signal strength |
strength
| Parameter | Value |
|---|---|
| Read 01 03 00 06 00 | 01 03 04 00 VM: Main version number |
| firmware 02 24 0A | VM VS VC CL VS: Sub-version number |
| version | CH VC: Revised version number |
BH1: High 8 bits of baud rate BH2: Secondary high 8 bits of
| Parameter | Value |
|---|---|
| 01 06 00 83 BH1 | 01 06 00 83 baud rate BL1: Secondary low 8 bits of baud |
| BH2 CL CH | BH1 BH2 CL CH rate |
| Set baud rate 01 06 00 84 BL1 | 01 06 00 84 BL2: Low 8 bits of baud rate For example: |
| BL2 CL CH | BL1 BL2 CL CH Set baud rate to 9600 |
(0x00002580): BH1=00 BH2=00 CL=78 CH=22, BL1=25 BL2=80 CL=D2 CH=D3 IH: High 8 bits of slave ID
Modify slave 01 06 00 85 IH IL 01 06 00 85 IH IL: Low 8 bits of slave ID For example: ID CL CH IL CL CH Modify slave ID to 0x0002:
IH=00 IL=02 CL=19 CH=E2 FH: High 8 bits of frame rate
Modify frame 01 06 00 86 FH 01 06 00 86 FL: Low 8 bits of frame rate For example: rate FL CL CH FH FL CL CH Modify (0x0064): frame rate to 100
FH=00 FL=64 CL=69 CH=C8 LH: High 8 bits of sampling frequent consumption mode in low power
| Parameter | Value |
|---|---|
| Low power 01 06 00 88 LH | 01 06 00 88 LL: frequent Low 8 in bits low of sampling power |
| consumption LL CL CH | LH LL CL CH consumption mode |
| mode | For example: Set it to 5Hz low power |
consumption mode,
LH=00 LL=05 CL=C9 CH=E3
Save setting 01 06 00 80 00 01 06 00 80 00 Save and reboot to take effect
COMMUNICATION PROTOCOL
00 88 22 00 88 22
| Parameter | Value |
|---|---|
| Disable 01 06 00 82 00 | 01 06 00 82 00 Save and reboot to take effect |
| Modbus 01 E8 22 | 01 E8 22 |
| Restore 01 06 00 89 00 | 01 06 00 89 00 |
| default 00 58 20 | 00 58 20 |
Warning 1 RTU mode is only supported for communication in serial communication.
For example:
1) Enable Modbus protocol in RS-485 serial communication mode: 5A 05 15 01 75 //Enable Modbus protocol 5A 04 11 6F //Save settings Enter Modbus protocol mode after rebooting.
2) Disable Modbus protocol: 01 06 00 82 00 01 E8 22 //Default address is 0x01, disable Modbus protocol 01 06 00 80 00 00 88 22 //Default address is 0x01, save setting Exit Modbus protocol after rebooting.
3.2 CAN Communication Protocol
3.2.1 Communication Protocol
The CAN communication protocol of TF02-i supports customer-defined protocol parameters or customized services, and the CAN protocol baud rate and ID can be modified. The CAN protocol is shown in Table 3- 9. Table 3- 9 CAN communication protocol of TF02-i
Characteristics Default values Communication interface CAN Baud rate 250kbps Transmitting ID 0x00000003 Receiving ID 0x00000003 Frame format Standard frame
Warning 1 0 is the broadcast ID, the transmitting and receiving ID cannot be set to 0. 2 The following baud rates are supported: 1000kbps,900 kbps,800 kbps, 666 kbps,500 kbps,400 kbps,250 kbps,200 kbps,160 kbps,125 kbps,
COMMUNICATION PROTOCOL
100 kbps.
3.2.2 CAN Communication Data Frame
The data protocol of CAN is shown in Table 3- 10. Each data frame consists of 8 bytes and the data contains the distance (unit: cm), signal strength and timestamp (unit: ms). Table 3- 10 The date frame format of CAN communication
| Parameter | Value |
|---|---|
| Data byte | Definition Description |
| Byte0 | Dist_L Low 8 bits of distance |
| Byte1 | Dist_H High 8 bits of distance |
| Byte2 | Strength_L Low 8 bits of signal strength |
| Byte3 | Strength_H High 8 bits of signal strength |
| Byte4 | Timestamp Low 8 bits of timestamp |
| Byte5 | Timestamp Secondary low 8 bits of timestamp |
| Byte6 | Timestamp Secondary high 8 bits of timestamp |
| Byte7 | Timestamp High 8 bits of timestamp |
3.2.3 CAN Bus Network
The CAN bus network is mainly hung in CAN_H and CAN_L, and each node performs serial differential transmission of signals through two lines. In order to avoid signal reflection and interference, it is recommended to connect 120Ω end point resistors at both ends of the bus, as shown in Figure 3- 1.
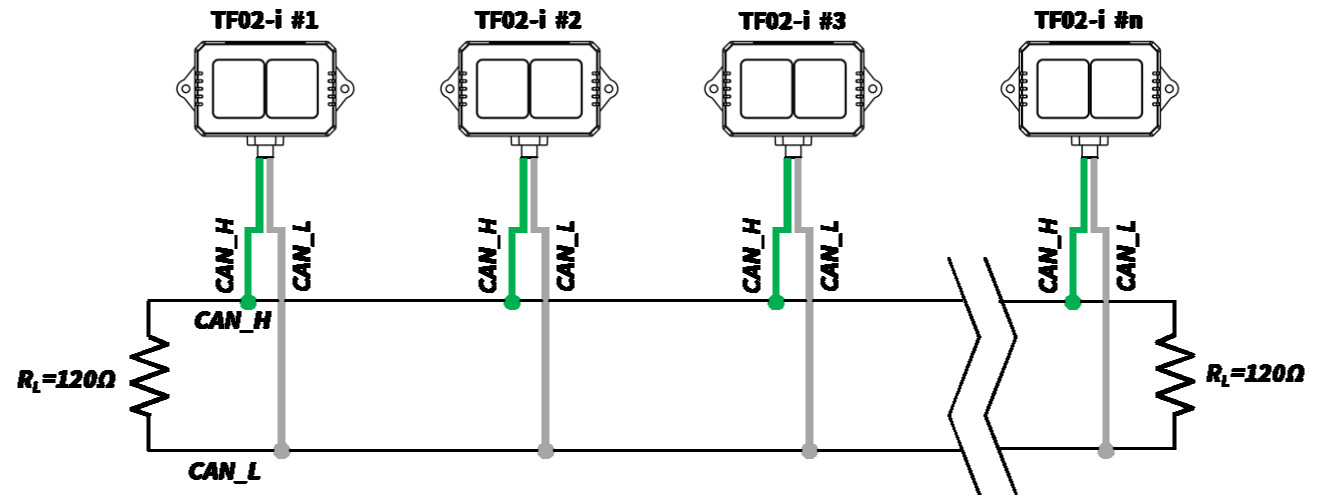
Figure 3- 1 CAN bus network of TF02-i
Note It is recommended to contact Benewake to communicate the details of use to complete networking requirements.
COMMUNICATION PROTOCOL
3.2.4 Parameter Configuration of CAN Communication
The configuration command format of CAN communication is shown as below. Table 3- 11 The configuration command format
| Parameter | Value |
|---|---|
| Byte 0 1 | 2 3 4 5-8 9-12 13 |
| Description Header Length | ID Type Baudrate Recv_id Trans_id Check_sum |
| Default 0x5A 0x0E | 0x51 0 0x08 0x00000003 0x00000003 SU |
Type: 0(Standard Frame), 1(Extended Frame); Recv_id: TF02-i receiving ID, Little Endian; Send_id: TF02-i transmitting ID, Little Endian. Baudrate: The code of baud rate, default 250kbps, corresponding to 0x08. The relation between baud rate(unit: kbps) and Byte4 is shown as below: Table 3- 12 The byte4 value corresponds to the baud rate
| Parameter | Value |
|---|---|
| Byte4 value | 0 1 2 3 5 |
| Baud rate (unit: kbps) | 1000 900 800 666 500 |
| Byte4 value | 8 10 11 14 16 |
| Baud rate (unit: kbps) | 250 200 160 125 100 |
Example of configuration: Example1: Standard frame, Baud rate 500kbps, receiving ID=0x00000010, transmitting ID=0x00000020 Command: 5A 0E 51 00 05 10 00 00 00 20 00 00 00 EE Example2: Extended Frame, Baud rate 250kbps, receiving ID=0x0000AABB, transmitting ID=0x0000CCDD Command: 5A 0E 51 01 08 BB AA 00 00 DD CC 00 00 D0 3.2.5 Other Parameter Configuration
Table 3- 13 General parameter configuration of TF02-i
| Parameter | Value |
|---|---|
| Function Command | Response Description |
| Read firmware 5A 04 01 5F | 5A 07 01 V1 V2 Version V3.V2.V1 |
| version | V3 SU |
| 5A 06 03 LL | 5A 06 03 LL HH 1-100Hz, default 100Hz |
| Frame rate ① HH SU | ① SU LL: Low 8 bits of frame rate |
HH: High 8 bits of frame rate
| Parameter | Value |
|---|---|
| Trigger 5A 04 04 62 | Data frame Set frame rate to 0, detection can |
| detection | be triggered with this command |
| System reset ③ 5A 04 02 60 | 5A 05 02 00 61 Succeeded |
5A 05 02 01 62 Failed
COMMUNICATION PROTOCOL
Disable/Enable 5A 05 07 00 66 5A 05 07 00 66 Disable data output output 5A 05 07 01 67 5A 05 07 01 67 Enable data output
The default setting is:
| Parameter | Value |
|---|---|
| Strength | When strength is below 60, make |
| threshold and 5A 07 22 XX LL | 5A 07 22 XX LL distance output 4500cm: |
| distance under | HH SU HH SU XX=60/10=6(DEC)=06(HEX) |
| threshold | 4500(DEC)=1194(HEX) |
LL=94,HH=11
| Parameter | Value |
|---|---|
| Restore to 5A 04 10 6E | 5A 05 10 00 6F Succeeded |
| factory settings | 5A 05 10 01 70 Failed |
| Save setting ④ 5A 04 11 6F | 5A 05 11 00 70 Succeeded |
5A 05 11 01 71 Failed
Enable/Disable 5A 05 60 01 C0 5A 05 60 01 C0 Enable 120Ω terminal resistor 120Ω terminal 5A 05 60 00 BF 5A 05 60 00 BF Disable 120Ω terminal resistor resistor ⑤
Warning 1 The customized frame rate should be calculated by the formula: 200/n (n is an integer with ≥ 2). 2 SU is checksum, checksum is disable by default. 3 Please keep power on and wait 1s after sending system reset command, otherwise the settings will not take effect. 4 After parameters configuration, send saving settings command to save the configuration, otherwise the settings will not take effect. 5 120Ω terminal resistor is disable in default.