
Technical documents
TF03 Series User Manual
TF03 Series User Manual
TF03 Series User Manual
Preface
This user manual contains the introduction, use and maintenance of TF03 series LiDAR. Please read this manual carefully before formal use, and strictly follow the steps described in the manual during use to avoid product damage, property loss, personal injury or/and violation of product warranty terms. If you encounter problems that cannot be solved during use, please contact Benewake staff for assistance.
Contact Details Official website: https://ai.benewake.com/en/products/tf03/ For technical questions, please contact: support@benewake.com For sales inquiries or to request brochure, please contact: bw@benewake.com Contact number: +86-135 8178 8602
Headquarter Address Benewake (Beijing) Co., Ltd. 3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China
Copyright Notice This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer The TF03 series product is constantly being improved, and its specifications and parameters will undergo iterative changes. Please refer to the official website for latest version.
Contents
Contents........................................................................................................................................................................................................................3 1. Laser Safety Information..................................................................................................................................................................................1
2. Installation and Maintenance..................................................................................................................................................................... 1 3. Product Overview...............................................................................................................................................................................................2 Measuring principle...................................................................................................................................................................................... 2 Technical Specifications........................................................................................................................................................................... 3 Structural Appearance..............................................................................................................................................................................4 Connector...........................................................................................................................................................................................................5
4. Communication Protocol.............................................................................................................................................................................. 6 UART, RS485, RS232 Communication................................................................................................................................................6
Communication protocol............................................................................................................................................................... 6 Data Frame ............................................................................................................................................................................................. 6
RS485 Modbus Protocol.............................................................................................................................................................................7 CAN Communication...................................................................................................................................................................................9
Communication protocol............................................................................................................................................................... 9 Data Frame ............................................................................................................................................................................................. 9
Custom configuration instructions.....................................................................................................................................................11 CAN networking..................................................................................................................................................................................10 Protocol description..........................................................................................................................................................................11 Common configuration instructions........................................................................................................................................11 Command editing............................................................................................................................................................................. 13
1. Laser Safety Information The LiDAR contains IR and invisible laser spots. IR laser: Wavelength 905nm; Class 1 according to IEC 60825-1:2014, EN 60825-1:2014+A11:2021.
CAUTION! Use of controls, adjustments or performance of procedures other than those specified herein may result in hazardous radiation exposure.
2. Installation and Maintenance
CAUTION! This laser product is classified as Class 1 during operational procedures. When the ranging feature is activated, the laser emitter of the LiDAR module may emit laser radiation, therefore, the LiDAR should NOT be aimed at humans and animals to ensure safety.
This product is designed and calibrated for installation with exposed lenses. If a protective window needs to be added in front of the lens, it is necessary to ensure the use of materials with high transmission at 905nm wavelength and anti-reflective coating. Avoid the presence of smoke and fog in the detection field. Avoid condensation. Avoid direct exposure to moisture and water. Do not use rough fabric or dirty towels or aggressive products to clean the laser lenses. Do not use a supply voltage higher than the maximum required in the specifications to power the product. Clean the laser lenses with compressed air. When needed, wipe the laser lenses only with a soft, clean microfiber cloth. Make sure the sensor is securely mounted to prevent false readings or damage. Only trained and qualified personnel may install, setup and repair the LiDAR.
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
3. Product Overview
Measuring principle TF03 series is a typical Pulse Time of Flight (PToF) sensor. TF03 series emits a narrow pulse laser, which is collimated by the transmitting lens, which enters the receiving system after being reflected by the measured target and is focused on the APD detector by the receiving lens. The time between the transmitted signal and the received signal is calculated through the circuit amplification and filtering, and the distance between TF03 series and the measured target can be calculated through the speed of light.
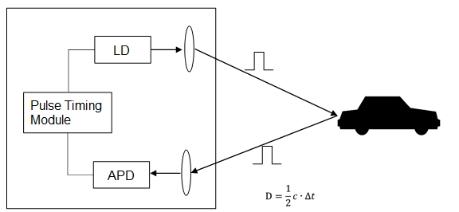
Pulsed time of flight
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
Technical Specifications
Performance Parameters
| Model | TF03-100 | TF03-180 |
|---|---|---|
| Detection range ① | 100 m @ 90% ref. 40 m @ 10% ref. | 180 m @ 90% ref. 70 m @ 10% ref. |
| Blind zone | ≤ 0.1 m | |
| Accuracy ① | ± 10 cm (< 10 m) , 1% (≥ 10 m) | |
| Repeatability ① | < 3 cm @ 1 σ | |
| Distance resolution | 1 cm | |
| Default frame rate | Up to 9,800 Hz (1 ~ 9,800 Hz configurable, default 100 Hz) | |
| Ambient light resistance | 100 KLux |
Optical Parameters
| Parameter | Value |
|---|---|
| Light source | EEL |
| Central wavelength | 905 nm |
| FoV ② | < 0.5° |
| Eye safety | Class1 (IEC 60825-1:2014; EN 60825-1:2014+A11:2021) |
Mechanical and Electrical Parameters
| Parameter | Value |
|---|---|
| Average power consumption ③ | ≤ 800 mW |
| Peak current ③ | < 480mA @ 12V |
| Power supply | DC 5V ~ 24V |
| Logical voltage | 3.3 V TTL |
| Connector | Molex standard 7pin terminal, model MH1.25-7P-W/B |
| Operating temperature | - 25 ℃ ~ + 60 ℃ |
| Storage temperature | - 40 ℃ ~ + 85 ℃ |
| Protection level | IP67 |
| Typ. Dimensions ② | 44.0 mm x 43.0 mm x 32.0 mm |
| Cable length ② | 70 cm |
| Typ. Weight ② | 86 ± 3g (excluding cables) |
Communication Protocol
Communication Interface UART / CAN (Can be switched by command), RS232, RS485
Notes: 1. When all the light spots fall on the target object, the accuracy, distance resolution, and repeatability
are measured under the conditions of a diffuse reflection whiteboard (90% reflectivity) at 25 ℃ indoors;
2. The weight and size are typical values for reference only. For detailed tolerance parameters, please consult the technical personnel of Benewake;
3. Measured at a temperature of 25 ℃, 100 Hz;
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
Structural Appearance The overall appearance of the LiDAR is as shown in the figure below:
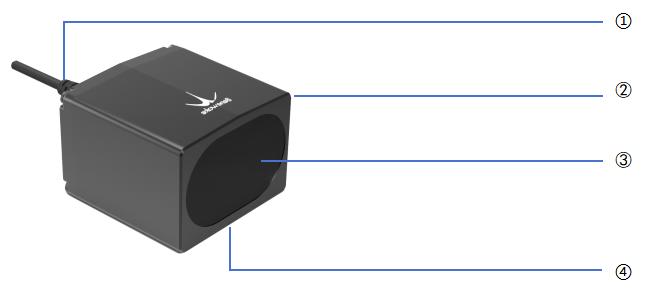
TF03 series Appearance
1 Cable with male connector, Molex SD-51021-007, 7pin also called MH1.25-7P-W/B 2 Laser window (Receiving) 3 Laser window (Emitting) 4 3mm diameter hole (6mm deep) for mounting (x6)
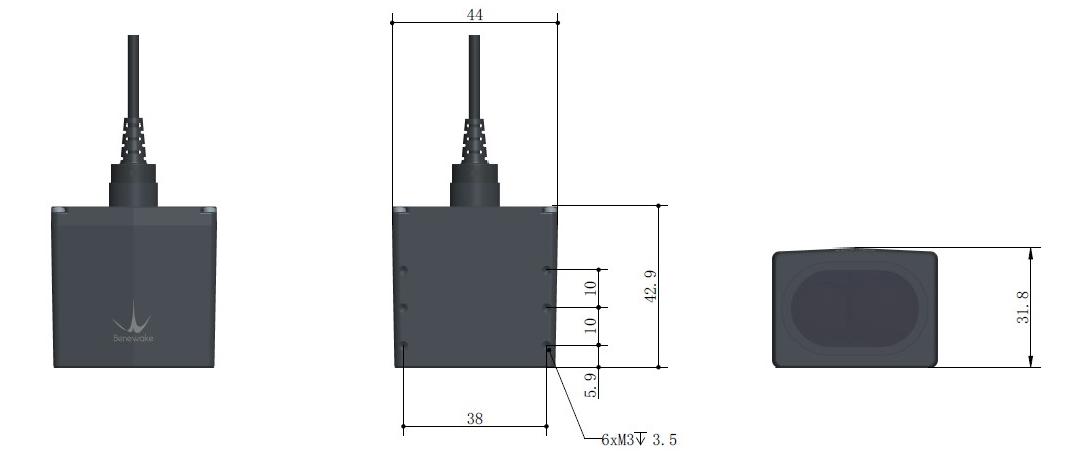
Unit: mm
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
Connector TF03’s cable has six 26 AWG wires. The connector is Molex SD-51021-007 1.25 W/B-7Pin also called MH1.25-7P-W/B.
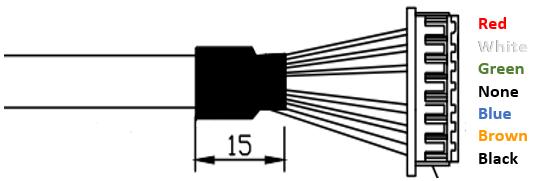
Male connector, Molex SD-51021-007 1.25 W/B-7Pin
Pin assignment on 7-pin male connector
| Parameter | Value |
|---|---|
| Pin Signal | Color Function |
| 1 VCC | Red Supply voltage DC 5 ~ 24V |
| 2 RS-485-B/RS-232-RXD/CAN_L | White Rx/CAN-BUS Low |
| 3 RS-485-A/RS-232-TXD/CAN_H | Green Tx/CAN-BUS High |
| 4 N/A | N/A N/A |
| 5 UART_RXD | Blue UART Receive |
| 6 UART_TXD | Brown UART Transmit |
| 7 GND | Black Ground |
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
4. Communication Protocol The TF03 series products are divided into three independent versions. The UART/CAN version supports dual communication interfaces of UART and CAN. Users can choose to connect the corresponding cables and terminals according to their needs, and then activate the corresponding protocol output through command switching. The LiDAR defaults to UART protocol output; The RS485 and RS232 versions support corresponding protocol data output, and can also send instructions to the LiDAR to change configuration through the built-in integrated UART serial port. UART, RS485, RS232 Communication
Communication protocol
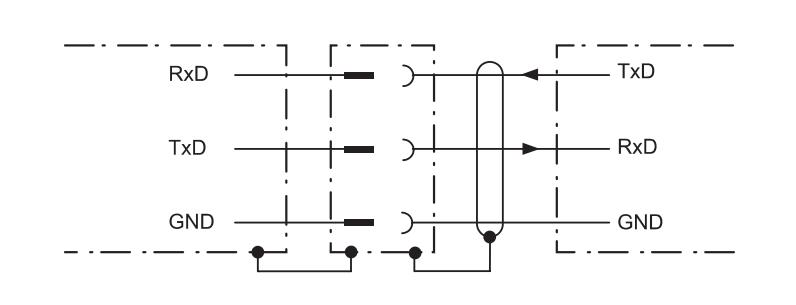
UART Interface Wiring Diagram
To connect two devices for UART communication, the transmitter's TxD should be connected to the receiver's RxD, and the receiver's TxD should be connected to the transmitter's RxD. The TF03 series UART interface adopts the UART-LVTTL interface, with an output level of LVTTL level (3.3 V). The UART, RS232, and RS485 communication protocols are shown in the following table: UART Communication protocol details
| Parameter | Value |
|---|---|
| Character | Value |
| Baud rate | 115200 |
| Data bit | 8 |
| Stop bit | 1 |
| Parity | None |
Baud rate can be set to 9600, 14400, 19200, 38400, 56000, 57600, 115200, 128000, 230400, 256000, 460800, 500000, 512000, 600000, 750000, and 921600. If other value were set, TF03 series will set it to 115200. Data Frame Each data frame under the UART interface contains distance and signal strength and consists of 9 bytes of hexadecimal values. Both distance and signal strength are represented by 2 bytes each,
| Parameter | Value |
|---|---|
| arranged in little-endian format . For details, refer to the table below: Standard Data Frame Format | |
| Data Byte 0 | 1 2 3 4 5 6 7 8 |
| Description Header Header | Distance Signal Strength Reserved Checksum |
| Typical Value 0x59 0x59 | byte Low High byte byte Low byte High 0x00 0x00 Sum |
Among them, "signal strength" represents the strength of the reflected light signal received by the LiDAR, and the value is related to the reflectivity and distance of the detected object. The lower the reflectivity and the farther the distance, the smaller the signal strength value will generally be. Low signal strength may affect the accuracy of distance measurement and even fail to achieve the required
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
signal-to-noise ratio, resulting in the phenomenon of outputting "over range values". The range of signal strength values is 10 ~ 4000. When the signal strength is below 40, TF03 will output an over range value. During normal distance measurement, the range of signal strength variation is 40 ~ 1200; When measuring high reflectivity objects, the signal strength will exceed 1500.
RS485 Modbus Protocol The TF03 Modbus uses a 2-wire interface; see the physical interface description for wire sequence. For parity and baud rate settings, refer to the communication protocol and data format. Custom parameter configuration requires switching to serial port mode to set the baud rate. The TF03 RS485 interface operates in half-duplex mode. For reliability reasons, using baud rates above 115200 is not recommended. When the Modbus protocol is enabled, the command format for reading distance from the TF03 via Modbus is as follows: TF03 RS485 Modbus Command Protocol
| Parameter | Value |
|---|---|
| Address Field Function Code | Register Address Number of Registers CRC_low CRC_high |
| 01 (Default) 03 | 00 00 00 01 xx xx |
| TF03 RS485 Modbus Data Protocol Function | Data |
| Address Field Code | Length Dist_high Dist_low CRC_low CRC_high |
| 01 (Default) 03 | 02 xx xx xx xx |
Modbus Function Codes Supported by TF03 Function Code Description 03 Read Registers 06 Write Single Register TF03 RS485 Modbus Function Code (03) Accessible Register List Register
| Parameter | Value |
|---|---|
| Address Definition | Description |
| 00 00 Dist | Distance Value |
| 00 01 Strength | Signal Strength Value |
| 00 03 Timestamp High 16 bits | Timestamp high 2 bytes, relative time since TF03 startup, unit: ms |
| 00 04 Timestamp Low 16 bits | Timestamp low 2 bytes, relative time since TF03 startup, unit: ms |
| 00 06 Software Version High 16 bits | 00 + Major Version Number |
00 07 Software Version Low 16 bits Minor Version Number + Revision Number TF03 RS485 Modbus Function Code (06) Accessible Register List
| Parameter | Value |
|---|---|
| Register Address Definition | Description |
| 00 80 Save Configuration | Writing any value to this register will execute the save configuration operation. |
| 00 81 Shutdown/Reboot | Register value description: 0-Shutdown (not supported yet); 1-Reboot |
| 00 82 Disable Modbus Protocol | 1-Disable Modbus protocol |
| 00 83 Baud Rate High | Configure baud rate, takes effect after saving and restarting. |
| 00 84 Baud Rate Low | Configure baud rate, takes effect after saving and restarting. |
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
00 85 Slave ID Configure device address, takes effect after saving and restarting. 00 86 fps Configure frame rate, takes effect after saving and restarting.
All register addresses are in hexadecimal. Register values are all defined as 16-bit. After configuring parameters, they will only take effect after saving the configuration and restarting the device.
Common Modbus Commands The default interface for the TF03 Industrial version is the universal RS485 interface protocol. If you need to use the Modbus protocol, you must enable it using a command. The enable command is shown in the table below: Function Command Successful Return Value Description
Takes effect after saving and restarting. This
Enable Modbus Protocol 5A 05 6F 00 CE 5A 05 6F 00 CE command only works under the universal RS485
interface. This command only works
Configure Modbus Device Address 5A 05 70 ADDR SU 5A 05 70 00 CF under the universal RS485
interface.
TF03 only supports RTU mode for communication over serial links. The LiDAR's default Modbus address is 0x01. The commands in the tables are edited according to this default address. If the Modbus address is modified, the first byte in the corresponding command must be modified accordingly to take effect. The commands in the table below only take effect when the Modbus protocol is enabled. Do not send commands not listed in the table. TF03 RS485 Modbus Protocol Common Command Set
| Parameter | Value |
|---|---|
| Function Command | Successful Return Value Description |
| Get Distance 01 03 00 00 00 01 84 | 01 03 02 DH DL CL DH, DL are the high 8 bits and low 8 bits of Distance, respectively; CL, CH |
| Value 0A | CH are the low 8 bits and high 8 bits of the CRC. |
| Get Distance 01 03 00 00 00 02 | 01 03 04 DH DL SH DH, DL are the high 8 bits and low 8 bits of Distance, respectively; SH, SL |
| and Strength Values C4 0B | SL CL CH are the high 8 bits and low 8 bits of |
| Get Version 01 03 00 06 00 02 24 | 01 03 04 00 VM VS Strength. VM, VS, VC are the major, minor, and |
| Number 0A | VC CL CH revision version numbers, respectively. BH1, BH2, BL1, BL2 are the high, second |
| Set Baud 01 06 00 83 BH1 BH2 CL CH | 01 06 00 83 BH1 BH2 CL CH high, second low, and low bytes of the baud rate, respectively. |
| Rate 01 06 00 84 BL1 BL2 CL CH | 01 06 00 84 BL1 BL2 CL CH Example: Set baud rate to 9600: BH1=00 BH2=00 CL=78 CH=22, BL1=25 |
BL2=80 CL=D2 CH=D3 IH, IL are the high and low bytes of the
Modify Slave ID 01 06 00 85 IH IL CL CH 01 06 00 85 IH IL CL CH ID. Example: Modify ID to 2:IH=00 IL=02
CL=19 CH=E2 FH, FL are the high and low bytes of
| Parameter | Value |
|---|---|
| Modify Output 01 06 00 86 FH FL CL | 01 06 00 86 FH FL CL the frame rate. |
| Frame Rate CH | CH Example: Modify frame rate to 100: FH=00 FL=64 CL=69 CH=C8 |
| Save Configuration 01 06 00 80 00 00 88 22 | 01 06 00 80 00 00 88 22 Takes effect after saving and restarting. |
| Disable Modbus 01 06 00 82 00 01 E8 | 01 06 00 82 00 01 E8 Takes effect after saving and |
| Protocol 22 | 22 restarting. |
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
CAN Communication The TF03 series CAN interface supports the DroneCAN protocol. If needed, please enable it using custom configuration commands.
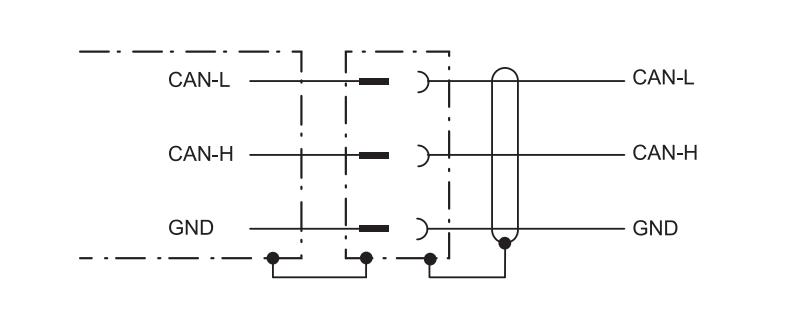
CAN Interface Wiring Diagram
Communication protocol
The CAN communication protocol of the TF03 series can be customized according to customer needs, with adjustable CAN baud rate, ID, and frame format. The content of the agreement is as follows:
TF03 Series CAN Interface Communication Protocol Parameter Value Baud Rate 1 Mbps Receive ID Standard Frame: 0x3 Extended Frame: 0x3 Transmit ID 0x3 Frame Format Transmitted Frames: Standard Frame (default) Received Frames: Supports both Standard and Extended Frames
The CAN interface baud rate setting only supports commonly used baud rates, such as 20000, 33330, 40000, 50000, 66660, 80000, 83330, 100000, 125000, 200000, 250000, 400000, 500000, 666000, 800000, 1000000. If other values are set, TF03 will set it to 1000000. Data Frame Data frames under the CAN interface consist of 6 bytes of hexadecimal values, containing measured distance and signal strength, with the remaining bytes reserved. TF03 CAN Communication Data Frame Format
| Parameter | Value |
|---|---|
| Data Byte 0 | 1 2 3 4 5 |
| Description Distance (Low) | Distance (High) Signal Strength (Low) Signal Strength (High) Reserved Reserved |
| Typical Value DIST_L | DIST_H Strength_L Strength_H – – |
Among them, "signal strength" represents the strength of the reflected light signal received by the LiDAR, and the value is related to the reflectivity and distance of the detected object. The lower the reflectivity and the farther the distance, the smaller the signal strength value will generally be. Low signal strength may affect the accuracy of distance measurement and even fail to achieve the required signal-to-noise ratio, resulting in the phenomenon of outputting "over range values". The range of signal strength values is 10 ~ 4000. When the signal strength is below 40, TF03 will output an over range value. During normal distance measurement, the range of signal strength variation is 40 ~ 1200; When measuring high reflectivity objects, the signal strength will exceed 1500. Attention: When using CAN communication, if the LiDAR needs to output a frame rate exceeding 6000 Hz, please set the baud rate to 1 M to ensure data transmission quality.
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
CAN networking The CAN bus network operates via the CAN_H and CAN_L lines, enabling serial differential signal transmission between nodes. To minimize signal reflection and electrical interference, a 120-ohm termination resistor must be connected between CAN_H and CAN_L. The TF03 series includes a built-in 120-ohm termination resistor, disabled by default. To simplify network setup, you can enable the built-in resistor via command only on devices located at the two ends of the CAN network. This eliminates the need for additional external termination resistors.
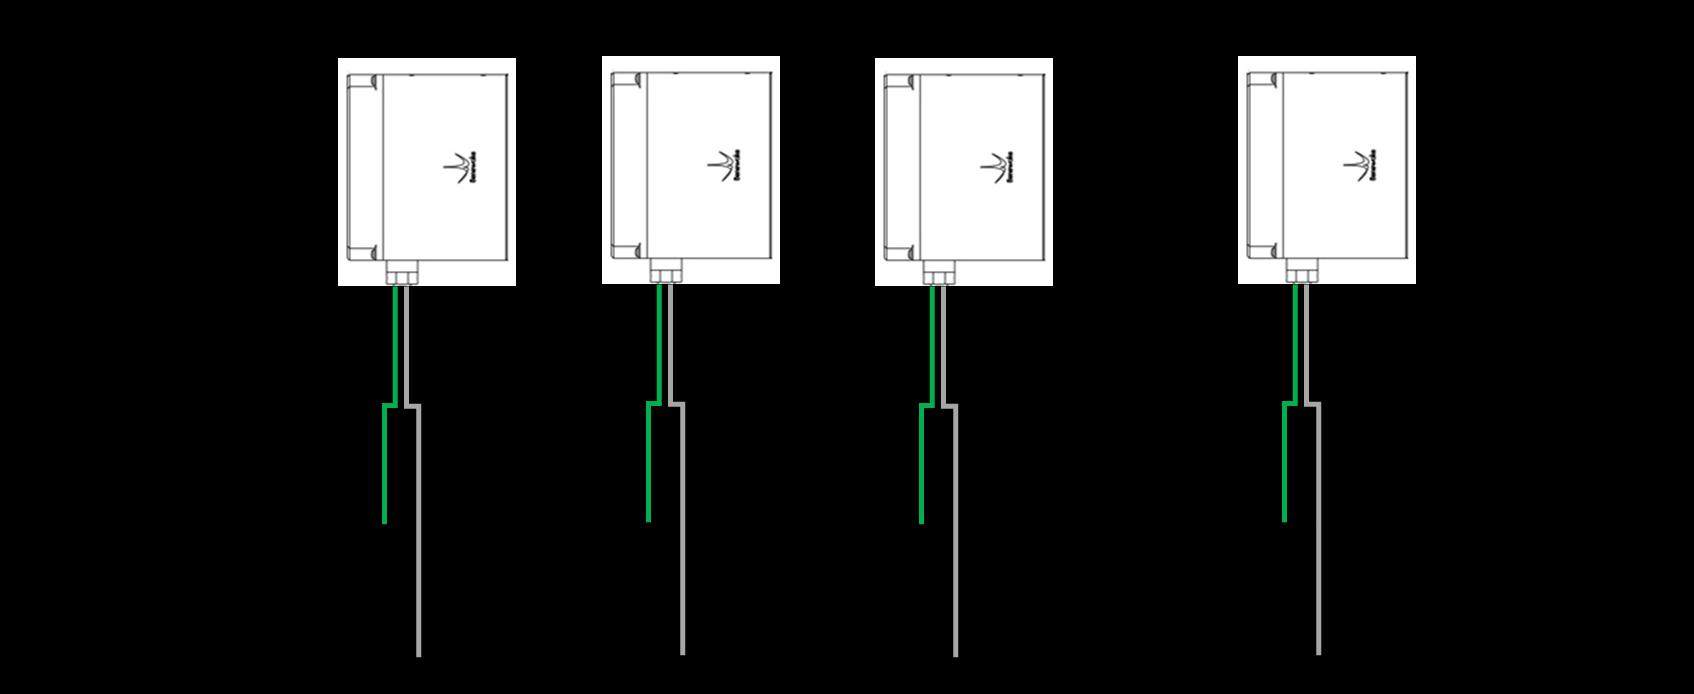
TF03 series CAN networking
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
Custom configuration instructions Protocol description To accommodate diverse customer requirements, the TF03 series allows users to configure operational parameters such as data format, frame rate, and more via command settings. Always strictly follow the instructions in this manual for product configuration and avoid sending undeclared commands. TF03 Series Command Protocol Format
| Parameter | Value |
|---|---|
| Data Byte Definition | Description |
| Byte 0 Header | Fixed value: 0x5A (hexadecimal). |
| Byte 1 Len | Total length of the command frame in bytes |
| Byte 2 ID | Command identifier (unique for each function). |
| Byte 3~N-2 Payload | Command-specific parameters (variable length and interpretation). |
| Byte N-1 Check Sum | Lower 8 bits of the sum of the first Len-1 bytes |
Common configuration instructions
| Parameter | Value |
|---|---|
| TTF03 RS485, RS232 Command Protocol List | Default |
| Description Downstream | Upstream Explanation Value |
| Get Firmware Version 5A 04 01 5F | 5A 07 01 VA VB VC SU Version is VC.VB.VA / |
| System Reset 5A 04 02 60 | 5A 05 02 00 61 / / |
Original LL: Frame Rate Low Byte, HH:
| Parameter | Value |
|---|---|
| Modify Frame Rate 5A 06 03 LL HH SU | Command Frame Rate High / |
| Enable Command | Original Byte |
| Trigger Mode 5A 05 07 00 66 | Command / / |
| Single Measurement 5A 04 04 62 | Data Frame Only effective in Command Trigger / |
| Trigger | Mode |
| Modify Baud Rate 5A 08 06 H1 H2 H3 H4 SU | Same as Downstream 115200 |
| Output Enable ON: 5A 05 07 01 67 OFF: 5A 05 07 00 66 | Original Command Enabled |
| Save Settings 5A 04 11 6F | Original Command / |
| Restore Factory Settings 5A 04 10 6E | Original Command / |
| Modbus Protocol Enable 5A 05 6F 00 CE | 5A 05 6F 00 CE / Disabled |
| Modbus Device Address 5A 05 70 ADDR SU | 5A 05 70 00 CF ADDR: Modbus device address 0x01 |
| TF03 CAN Command Protocol List | Default |
| Description Downstream | Upstream Explanation Value |
| Switch Communication TTL: 5A 05 45 01 A5 | 5A 05 45 00 A4 Takes effect after TTL |
| Interface CAN: 5A 05 45 02 A6 | restart |
| Configure | 5A 05 4F 00 AE Out-of-range value = (HH << 8) + 18000 |
| Out-of-Range Value 5A 06 4F LL HH SU | LL, unit: cm |
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
ID = (H4<<24) + (H3<<16) + (H2<<8) +
Configure Transmit ID CAN 5A 08 50 H1 H2 H3 H4 SU 5A 05 50 00 AF H1 0x03
Effective under CAN interface ID = (H4<<24) + (H3<<16) + (H2<<8) +
Configure Receive ID CAN 5A 08 51 H1 H2 H3 H4 SU 5A 05 51 00 B0 H1 0x03
Effective under CAN interface Baudrate (H4<<24) + (H3<<16) =
Configure CAN Baud Rate 5A 08 52 H1 H2 H3 H4 SU 5A 05 52 00 B1 + (H2<<8) + H1 1M
Effective under CAN interface
| Parameter | Value |
|---|---|
| CAN Frame Type Standard Frame: 5A 05 5D 00 BC | Standar |
| Setting Extended Frame: 5A 05 | 5A 05 5D 00 BC d Frame |
| 5D 01 BD Enable: 5A 05 84 00 E3 | Disable |
| DroneCAN Enable Disable: 5A 05 84 01 E4 | 5A 05 84 00 E3 d |
| Configure Offset 5A 06 69 LL HH SU | 5A 05 69 00 C8 Offset = (HH << 8) + LL, unit: cm 0 |
| Set CAN Termination Resistor Switch ON: 5A 05 91 01 F1 OFF: 5A 05 91 00 F0 | 5A 05 91 00 F0 Off |
| Enable Low Power 5A 05 83 01 E3 | Original Command Only under effective UART / |
| Mode | interface |
| Disable Low Power 5A 05 83 00 E2 | Original Command Only under effective UART / |
| Mode | interface |
Note: After using configuration commands to change one or more product parameters, please send the "Save Current Settings" command to write the changed parameters to the product. Otherwise, the parameters will revert to the last saved values after power cycling.
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·
Command editing This section describes the Command Channel of TF03 which is used to read and set TF03’s working parameters. The command channel is available via all the interfaces. A standard TF03 command consists of frame header, command length, command ID, parameters and checksum. Follow these steps to generate a command:
1. 2. Convert parameter from the decimal value to hexadecimal value Choose the right command ID and confirm its length
3. Fill the hexadecimal parameter into the command 4. Calculate the checksum and fill its low 8-bits into the command
Example: Setting Baud Rate to 460800 1. Identify Command ID and Length Assume the command ID is 0x06 and total length is 8 bytes (including header and checksum).
2. Convert 460800 to Hexadecimal 460800 → 0x00 07 08 00 (hex, little-endian).
3. Construct the Command Frame Header Len ID Param 1 Param 2 Param 3 Param 4 Checksum 0x5A 0x08 0x06 0x00 0x08 0x07 0x00
4. Calculate Checksum Sum: 0x5A + 0x08 + 0x06 + 0x00 + 0x08 + 0x07 + 0x00 = 0x77 (lower 8 bits). Final Command: 0x5A 0x08 0x06 0x00 0x08 0x07 0x00 0x77
© 202 5 Be n ew ak e (B e i ji n g) Co., Ltd. · Al l ri gh ts re se r ve d ·