
Applicable scenarios
Suitable for underwater or short-range distance measurement and compact sensor integration.
Condition: Bounded by the range, accuracy and operating conditions in the product datasheet.
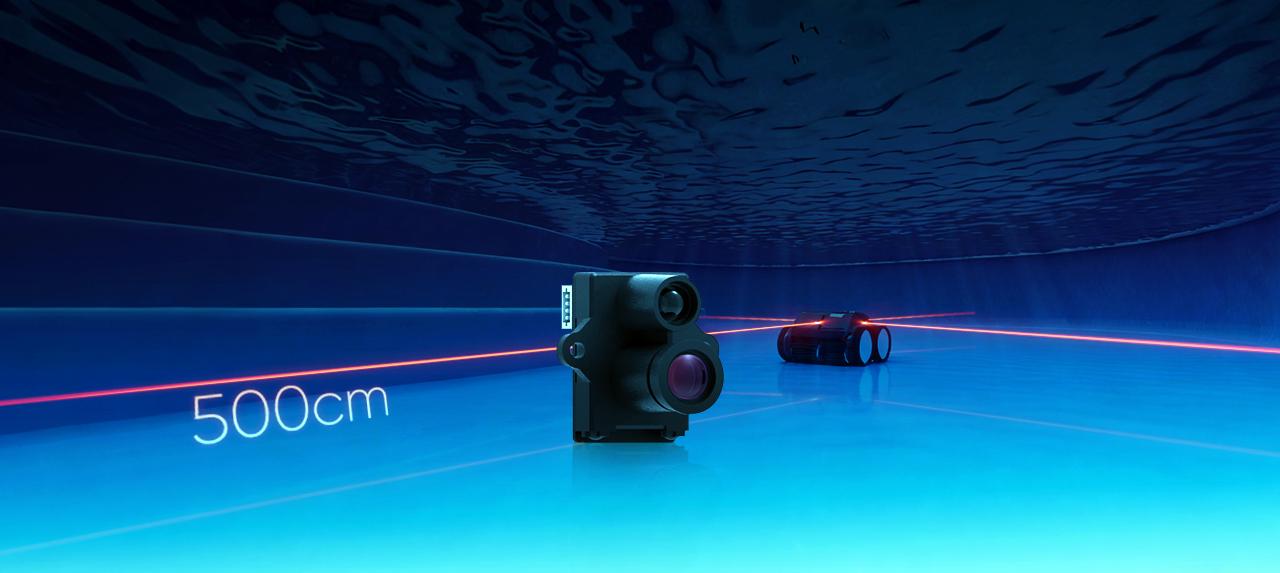
Adopting a dToF (direct Time-of-Flight) solution, the TF-UW500 maintains the compact design and low-power efficiency of its predecessor, while achieving a tenfold increase in detection range in low-turbidity water — enabling underwater robots to achieve breakthroughs in both precise mapping and stable positioning.
Key specifications
Need help confirming a selection or purchase details?
| Parameter | Value | Parameter | Value |
|---|---|---|---|
| Measuring range | 0.1 ~ 5 m | Detecting accuracy | < 3 cm (0.1 ~ 2 m) |
| Frame rate | 20 Hz | Interface | UART, I²C |
| Protection | Without enclosure | Dimensions | 24mm×16mm ×20.4mm |
| Power consumption | ≤ 0.5 W | Weight | < 5 g |
| Field of view | < 0.5° | Output data | 3.3 V TTL |
| Operating voltage | DC 5±0.2 V |
Suitable for underwater or short-range distance measurement and compact sensor integration.
Condition: Bounded by the range, accuracy and operating conditions in the product datasheet.
TF-UW500 is not intended for measurements beyond this model's datasheet range, accuracy or interface limits, and is not a substitute for certified redundant safety systems.
Condition: If the target requirement exceeds the specification boundary, complete a selection review or contact technical support first.
The TF-UW500 achieves a detection range exceeding 5 meters underwater at standard conditions (NTU < 0.5, 30% reflectivity, perpendicular beam incidence, water depth > 1 m). It has a blind zone of ≤ 0.1 m, making it unsuitable for very close-range targets beneath that threshold.
The TF-UW500 supports both UART and I²C interfaces, switchable by command. The default UART baud rate is 115200 (configurable), with 8 data bits, 1 stop bit, and no parity, using a 1.0 mm 4-pin connector (HC-1.0-4PWT) and 3.3 V TTL logic levels.
The TF-UW500 is specifically designed for outdoor pool cleaning robots operating under strong sunlight, leveraging its underwater capability, high ambient light resistance (100 KLux), and red laser wavelength. It is ideal for robotic pool navigation, water level detection, and obstacle avoidance in swimming pools and similar aquatic environments.
Within the 0.1–2 m range, the TF-UW500 offers accuracy better than 3 cm and repeatability better than 1 cm at 1σ confidence interval. The distance resolution is 1 mm, enabling precise underwater measurements for robotic navigation and level monitoring applications.
The TF-UW500 operates between 0 °C and +50 °C, with a storage temperature range of −20 °C to +70 °C. Note that it has no IP rating specified in the datasheet; waterproofing specifications should be confirmed with Benewake technical personnel before deployment in wet environments.
The TF-UW500 requires a DC 5±0.2 V power supply with average consumption of less than 500 mA (5 V × 100 mA). Peak inrush current at startup can reach 700 mA, so adequate power supply capacity with transient margin is recommended for stable operation.
The TF-UW500 measures 24.0 mm × 16.0 mm × 20.4 mm and weighs less than 5 grams excluding cables. These compact dimensions make it well-suited for integration into space-constrained robotic platforms and subsea equipment.
The TF-UW500 has a minimum blind zone of 0.1 m, so it cannot reliably detect targets closer than 10 cm. Additionally, the datasheet specifies no IP rating, meaning water-resistance integrity cannot be verified from published specs alone. Performance degrades at high turbidity levels (rated at NTU < 0.5); murky water significantly reduces detection range.
The TF-UW500 is Benewake's first underwater-rated single-point LiDAR with red laser (most competitors use NIR/850 nm). Unlike the dry-environment TF-mini/TF03 series, it features enhanced optical design for water transmission and ambient light rejection (100 KLux), though range is limited to >5 m versus >25 m for terrestrial TF models. Direct technical comparison with Lightware LW series underwater modules requires their full specifications.
The TF-UW500's UART and I²C interfaces enable integration with Arduino, PLC, embedded Linux systems, and ROS-based robotic platforms. The 3.3 V TTL logic levels are compatible with standard microcontroller GPIO; for 5 V systems, a level shifter is required. Specific integration examples (firmware libraries, ROS drivers, sample code) should be requested from Benewake support.