
技术资料
tf-luna 用户手册
TF-Luna User Manual
TF-Luna User Manual
Benewake (Beijing) Co., Ltd
PREFACE
Dear users: Thank you for choosing Benewake products. For the purpose of offering better operation experience to you, we hereby write this manual for an easier and simpler operation of our product, hoping to better solve the common problems you may meet. This user manual contains the relevant information on product introduction, usage and maintenance of TF-Luna, covers the product operation introduction and common problem solutions. Please read this manual carefully before using the product. Remember the precautions to avoid hazards, and please follow the described steps in the manual when using it.
If you have any problems in the process of usage, you are welcome to contact Benewake at any time for help.
Contact details Official website: https://ai.benewake.com/zh/products/tf-luna/ TEL:+86-10-5745 6983 Technical questions,please contact: support@benewake.com Consult sale information or request brochure,please contact: bw@benewake.com
Headquarters Address Benewake (Beijing) Co., Ltd. 3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China
Copyright Statement This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake.
Disclaimer As our products are constantly improving and updating, the specifications of TF-Luna are subject to change. Please refer to the official website for latest version.
CONTENTS
1 REVISIONS..............................................................................................................................................1 2 CAUTIONS.............................................................................................................................................. 2 2.1 About document........................................................................................................................2 2.2 About product............................................................................................................................2
| Parameter | Value |
|---|---|
| 2.3 Common errors and other notes | ............................................................................................. 2 |
| 3 PRINCIPLE DESCRIPTION AND KEY PARAMETERS | .............................................................................. 3 |
| 3.1 Ranging Principle | ...................................................................................................................... 3 |
| 3.2 Basic Characteristic Parameters | .............................................................................................. 3 |
3.3 Repeatability..............................................................................................................................4 3.4 Ranging Characteristics............................................................................................................4 4 APPEARANCE AND STRUCTURE........................................................................................................... 6 4.1 Appearance............................................................................................................................... 6
| Parameter | Value |
|---|---|
| 5 ELECTRICAL CHARACTERISTICS | ............................................................................................................ 7 |
| 6 FUNCTIONAL DESCRIPTIONS AND CONFIGURATION | ......................................................................... 8 |
| 6.1 Description about Line Sequence and Connection | ............................................................... 8 |
| 6.2 Serial Port Communication Protocol | ....................................................................................... 8 |
| 6.3 I 2 C Communication | .................................................................................................................... 9 |
| 6.4 Basic Data Output | ....................................................................................................................10 |
| 6.5 Continuous Ranging Mode | .....................................................................................................10 |
6.6 Trigger Mode............................................................................................................................11 6.7 On/off Mode.............................................................................................................................11 6.8 Amp Threshold........................................................................................................................ 12 6.9 Distance Limit.......................................................................................................................... 12
| Parameter | Value |
|---|---|
| 6.10 Power Saving Mode | .............................................................................................................. 12 |
| 6.11 Ultra-low Power Mode | ......................................................................................................... 13 |
| 6.11.1 Ultra-low Power Mode with Serial Port Communication | ...................................... 13 |
| 6.11.2 Ultra-low Power Mode with I2C communication | ................................................... 14 |
| 6.11.3 Caveats | ........................................................................................................................15 |
| 6.12 Single Frequency Mode | ........................................................................................................ 15 |
| 6.13 Additional notes | .................................................................................................................... 16 |
7 QUICK TEST GUIDE...............................................................................................................................17 7.1 Required tools for testing.......................................................................................................17 7.2 Steps......................................................................................................................................... 17 8 FIRMWARE UPGRADE..........................................................................................................................19 APPENDIX I SERIAL PORT OUTPUT FORMAT........................................................................................20
1. 9-byte/cm (Default).................................................................................................................. 20
2. PIX............................................................................................................................................... 20
3. 9-byte/mm................................................................................................................................. 20
4. 32-byte with timestamp........................................................................................................... 20
5. ID-0 output................................................................................................................................. 21
6. 8-byte/cm...................................................................................................................................21
| Parameter | Value |
|---|---|
| 7. Output with Device ID | ............................................................................................................... 21 |
| Appendix II Serial communication protocol | .......................................................................................22 |
| 1. Version information ID_GET_VERSION=0x01 | ..........................................................................22 |
| 2. System software restore ID_SOFT_RESET=0x02 | ..................................................................... 22 |
| 3. Output frequency ID_SAMPLE_FREQ=0x03 | .............................................................................22 |
| 4. Trigger mode ID_SAMPLE_TRIG=0x04 | ..................................................................................... 23 |
| 5. Output format setting ID_OUTPUT_FORMAT=0x05 | ................................................................23 |
| 6. Baud rate setting ID_BAUD_RATE=0x06 | ................................................................................. 24 |
| 7. Enable/disable output ID_OUTPUT_EN=0x07 | ........................................................................ 24 |
| 8. Enable/disable checksum comparison ID_FRAME_CHECKSUM_EN=0x08 | .......................... 25 |
| 9. I 2 C slave machine address configuration ID_I | 2 C_SLAVE_ADDR=0x0B .................................25 |
| 10. Restore default setting ID_RESTORE_DEFAULT=0x10 | ..........................................................25 |
| 11. Save current setting ID_SAVE_SETTINGS=0x11 | ....................................................................26 |
| 12. Output product bar code ID_READ_MANU_BIN=0x12 | ......................................................... 26 |
| 13. Get full-length version number ID_GET_FULL_VERSION=0x14 | .......................................... 27 |
| 14. Amp threshold setting ID_AMP_THRESHOLD=0x22 | .............................................................27 |
| 15. Switch between Single Frequency and Dual Frequency ID_ DEALIAS_EN =0x29 | ............ 28 |
| 16. Timestamp synchronization ID_TIMESTAMP_SYNC =0x31 | ................................................. 28 |
| 17. Enable/disable Power saving mode (ECO) ID_LOW_CONSUMPTION=0x35 | ..................... 28 |
| 18. Filter Setup ID_FILTER_BIT_MAP=0x39 | .................................................................................. 29 |
| 19. Distance limit setting ID_DIST_LIMIT=0x3A | .......................................................................... 29 |
| 20. Enable/disable on-off mode ID_ON_OFF_MODE=0x3B | ...................................................... 30 |
| 21. Read config by id ID_GET_CONFIG_PARA=0x3F | ................................................................... 30 |
| 22. Ultra-low Power Mode ID_ ULTRA_LOW_POWER_MODE=0x58 | .......................................... 30 |
| 23. Frequency Calibration ID_FREQ_CNT_CALIB=0x59 | .............................................................. 31 |
| Appendix III I2C register table | ............................................................................................................. 32 |
REVISIONS
1 REVISIONS
Version History Date No. A00 Original 2020.1.15
1. Old serial port formats are removed.
2. Module size and related pictures are updated.
A03 3. More description of function. 2020.3.15
4. I2C interface is now available.
5. Power supply voltage up to 3.7V-5.2V is now supported.
1. Removed “ Enable/disable low sample rate mode ID_LOW_SAMPLE_RATE=0x3E”.
2. Changed the definition of I2C register 0x25: 0x00 – LiDAR off, 0x01 – LiDAR on.
3. Changed the description of I2C register. Users should make sure that firmware version is above V1.0.7 when using I2C communication.
A05 4. Added the description on Amp with respect to ambient 2020.7.23
light overexposure.
5. Added Ultra-low Power Mode.
6. For I2C register 0x2E-0X31, changed the units of distance limit from centimeter to millimeter.
7. Added description on the Single Frequency Mode.
8. Added filter setup commands.
9. Added device ID into the output format.
CAUTIONS
2 CAUTIONS
2.1 About document This manual provides all essential information you may need during the usage of this product. Please read this manual carefully before using this product and make sure that you fully understand the contents of the manual. 2.2 About product The product can only be maintained and repaired by qualified professionals, and only original spare parts are permitted to use for performance and safety reasons. This product DOES NOT have polarity and over-voltage protection at all. Please wire and supply power according to the instructions. The working temperature of the product is from -10℃ to 60℃, please do not use it outside this temperature range to avoid risk and damage. The storage temperature of the product is from -20℃ to 75℃, please do not store it outside this temperature range to avoid risk and damage. For safety and performance, please DO NOT open the product casing or remove the IR-pass filter. 2.3 Common errors and other notes Detecting object with high reflectivity, such as mirrors, smooth floor tiles, and calm milk liquid. Blocking the product with any transparent objects, such as water or glasses. The product ’ s lens may be covered by dusts or dirt which may affect results, so please keep the lens clean. The exposed circuit board is electrostatic sensitive. Please do not touch the circuit board of the product barehanded. Please use ESD wrist strap or antistatic gloves to ground yourself if any operation is necessary; Otherwise, the product may be damaged by static electricity.
PRINCIPLE DESCRIPTION AND KEY PARAMETERS
3 PRINCIPLE DESCRIPTION AND KEY
PARAMETERS
3.1 Ranging Principle TF-Luna is using Time of Flight (ToF) principle to measure the distance and it periodically emits near infrared modulated waves. TF-Luna calculates the time by measuring the phase difference between the original wave and the reflection wave and uses that time to get relative distance, as shown in Figure 1.
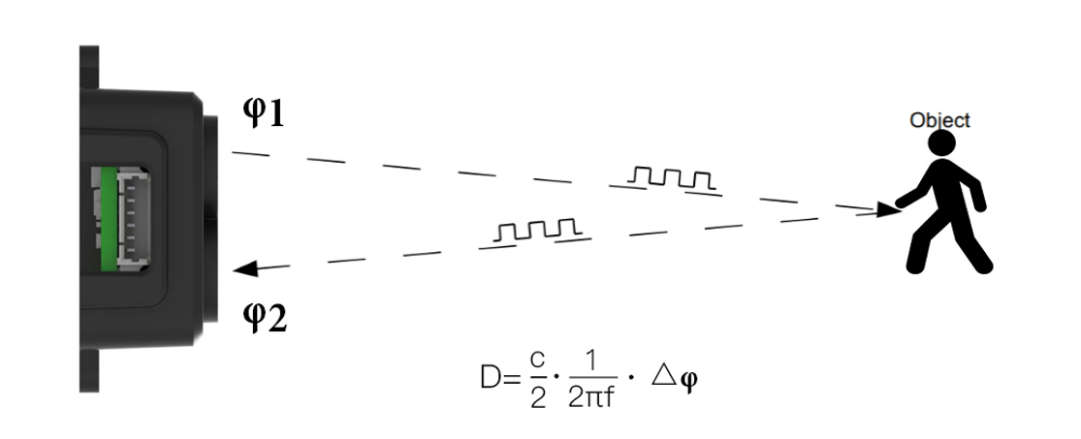
Figure 1 Schematics of ToF Principle
3.2 Basic Characteristic Parameters Table 1 Parameters specification of TF-Luna
| Parameter | Value |
|---|---|
| Description | Parameter value |
| Operating range | 0.2m~8m ① |
| Accuracy | ±6cm@ (0.2-3m) |
±2%@ (3m-8m)
Measurement unit cm (Default) Range resolution 1cm FoV 2° ② Frame rate 1~250 Hz ( adjustable ) ③
1) Operating r ange is measured indoor based on a standard whiteboard with reflectivity 90%.
2) This is theoretical value, real value may be different.
3) 100 Hz is default and only any factor (500/n, n can be any integer in [2, 500]) of 500Hz is available.
PRINCIPLE DESCRIPTION AND KEY PARAMETERS
3.3 Repeatability TF-Luna's ranging accuracy is positively correlated with the strength value (amp) and negatively correlated with the output frame rate (frequency). The tables below show the standard deviation (STD) using 100Hz output rate. These values are for reference only; various testing environments may give different results. Table 2 STD Amp correlation
Amp 100 200 400 1000 ≥2000 STD 3cm 3cm 2cm 1cm 0.5cm
Table 3 STD Dist correlation with 90% diffuse reflectance object
Dist 200cm 400cm 600cm 800cm Std 0.5cm 1cm 1.5cm 2cm
3.4 Ranging Characteristics TF-Luna minimizes the impact of external environment on ranging performance by optimizing light path and algorithm. TF-Luna’s ranging blind zone is 20 cm. Any distance output less than 20 cm is unreliable. The operating range of black and white targets is different: The operating range of TF-Luna detecting black target with 10% reflectivity is 0.2-2.5m; the operating range of TF-Luna detecting white target with 90% reflectivity is 0.2-8m. The ranging data is reliable only if the reflection surface fully covers the light spot, so the diameter of the object must at least the same as the diameter of the light spot, and that diameter depends on FoV of TF-Luna. The minimum diameter of the object surface can be determined by the following formula:
d = 2 ∗ D ∙ tan β
In the formula, d represents the minimum diameter, D is the distance of the object, and β is the half FoV of TF-Luna. Common values are shown in Table 4 for your convenience: Table 4 Distance and minimum diameter Distance (D) 1m 2m 3m 4m 5m 6m 7m 8m Minimum 3.5cm 7cm 10.5cm 14cm 17.5cm 21cm 24.5cm 28cm diameter (d) If the light spot reaches two objects with different distances as Figure 2, the output distance value (Dist) will be abnormal, which may cause error for high-accuracy applications. Please try to avoid this situation for better accuracy and performance.
PRINCIPLE DESCRIPTION AND KEY PARAMETERS
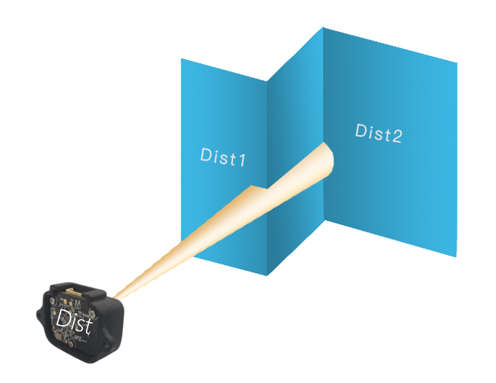
Figure 2 Detecting two objects at different location
APPEARANCE AND STRUCTURE
4 APPEARANCE AND STRUCTURE
4.1 Appearance
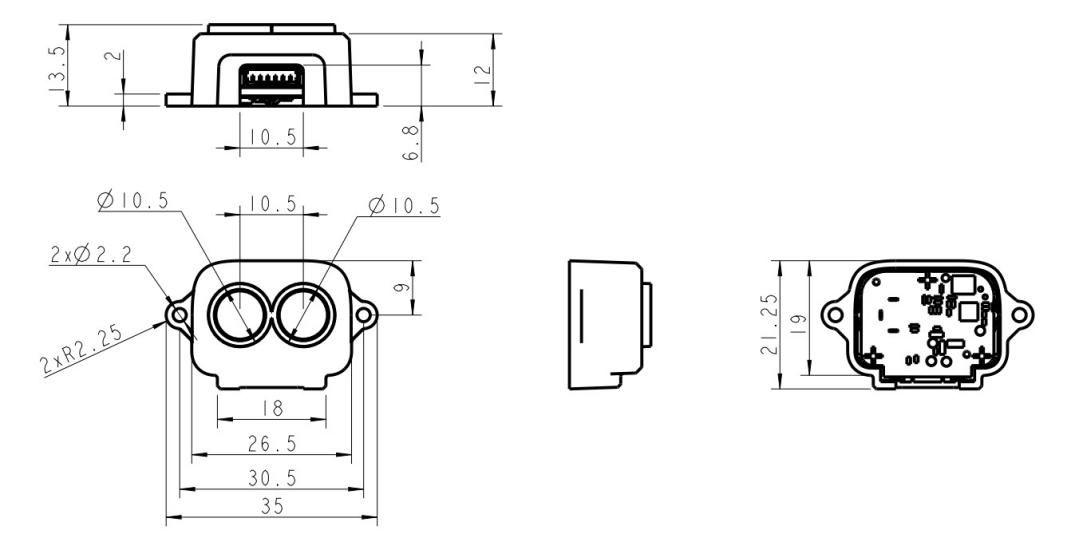
Figure 3 TF-Luna appearance and size drawing
ELECTRICAL CHARACTERISTICS
5 ELECTRICAL CHARACTERISTICS
Table 5 Major Electrical Parameters of TF-Luna
Description Value range Power supply voltage 3.7V-5.2V Average current ≤70mA Peak current 150mA Power consumption ≤350mW Communication signal LVTTL (3.3V) level
This product has no over-voltage nor polarity protection, so please make sure that the product is well connected, and the power supply voltage is inside the given range.
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
6 FUNCTIONAL DESCRIPTIONS AND
CONFIGURATION
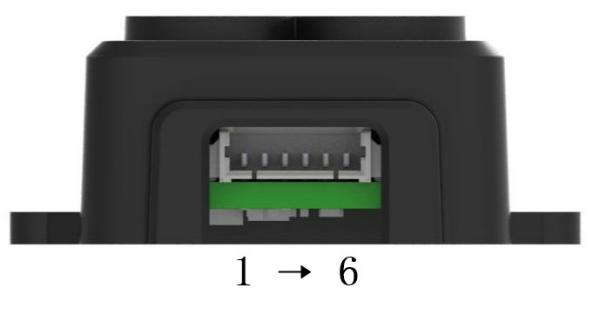
Figure 4 TF-Luna’s pin numbers
6.1 Description about Line Sequence and
Connection Table 6 The Function and Connection Description of Each Pin
| Parameter | Value |
|---|---|
| No. Function | Description |
| 1 +5V | Power supply |
| 2 RXD/SDA | Receiving/Data |
| 3 TXD/SCL | Transmitting/Clock |
| 4 GND | Ground |
| 5 Configuration Input | Ground: I2C mode |
Disconnected/3.3V: Serial port Communications mode
6 Multiplexing output On/off mode: Output
I2C mode: Data ready signal
6.2 Serial Port Communication Protocol Serial port communication starts when pin 5 is disconnected or connected to 3.3v. It will set TF-Luna receiving RXD on pin 2 and sending TXD on pin 3. The serial port
communication protocol is defined as follows: 8 data bits, 1 stop bit with no parity
check and default baud rate of 115200 bps. Serial port communication protocol data byte format:
byte 0 1 2 3~Len-2 Len-1 Description Head(0x5A) Len ID Payload Checksum
Head: Fixed 0x5A.
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
Len: The length of bytes from the head byte to check-sum at the end, and it has to be in between 4 to 255. ID: Indicates how to parse the payload data. Payload: Payload data segment, optional. Checksum: The lower 8 bytes of the sum from Head to Payload. Please check Appendix II Serial communication protocol for more information. Note: TF-Luna does not enable checksum check for sending data frames by default, that is, the Checksum at the end of the sending frame can be filled with any value..
| Parameter | Value |
|---|---|
| Thus, ANY value is acceptable on the Checksum byte, | unless checking of those bytes is |
| required. Please | check “ Enable/disable checksum comparison |
| ID_FRAME_CHECKSUM_EN=0x08 | ” in Appendix II Serial communication protocol to |
enable the feature. The instruction makes change immediately after sending, but the current setting is not saved and will be lost after reboot. User must use “ Save current setting ID_SAVE_SETTINGS=0x11 ” to save the change. The full save-current-setting hexadecimal sequence is 5A 04 11 00 in this case. 6.3 I 2 C Communication When pin 5 is connected to ground, TF-Luna enters I 2 C mode, then its pin 2 is used as SDA data and pin 3 is the SCL clock sending data. TF-Luna supports up to 400kps clock speed as slave machine and its default address is 0x10. For more information about I2C register table refer to Appendix III I2C register table. Note: In this document, the address of I2C slave device is a 7-bit value with value range [0x08, 0x77] ([08, 119] in decimal). For the first byte after I 2 C releases a start signal, the 7-bit address should be shifted leftward for one bit (i.e. multiplied with 2), and then filled with the read-write sign on the lowest bit. For TF-Luna, the default address of slave device is 0x10, the address for write operations is 0x20, and the address for read operations is 0x21. Write register timing: Start Slave W Ack Register Ack Data1 Ack … DataN Ack Stop
Addr Addr
Read register timing:
Start Slave Addr W Ack Register Addr Ack Stop
Start Slave Addr R Ack Data1 Ack … DataN Nack Stop Note that in the read register sequence, the host can directly generate the second Start
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
signal without generating the first Stop signal. The last Nack can also be an Ack signal. In the continuous ranging mode, the host must monitor pin 6 for synchronous signal and initiate the read data operation in time. Otherwise, it may cause an error by reading and updating the data register at the same time. In multi-machine bus mode, use command to trigger reading is strongly recommended.
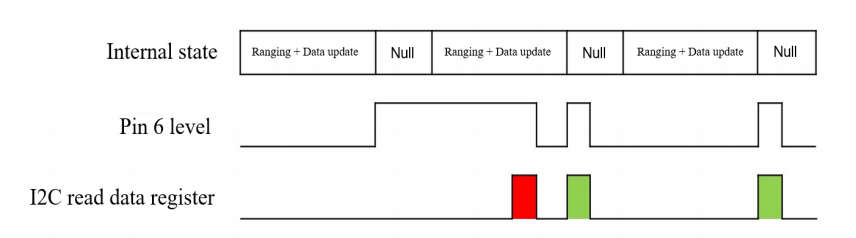
Figure 5 Timing of reading data register in I2C mode
Pin 6 is normal low level and it switches to high as soon as the data is updated. It switches to low level only if a read operation on any register is done. Therefore, I2C host must read the register when receive a high level on pin 6 in the continuous ranging mode. As the figure has shown above, the first result in red is unreliable and the rest two in green are accurate. After a write operation on the I 2 C register, it takes TF-Luna some time to process. If users need to read the value from the register for validation purposes, we recommend waiting for 100ms after the write operation, prior to the next read operation. 6.4 Basic Data Output TF-Luna normally provides these data below: Distance (Dist): Default in centimeters. Signal strength (Amp): Distance value is unreliable when receiving signal is overexposed (Amp = 0xFFFF) or too low (Amp < 100). Normally, Amp value should not be above 30000. When Amp is above 32768, it indicates that TF-Luna has detected an ambient light overexposure, for instance, when it faces the sun in outside. Chip Temperature (Temp): Celsius degree = Temp/8 - 256℃ TF-Luna supports various serial format, please check Appendix I Serial port output format for more information, and the default setting is 9-bytes/centimeter. Format setting is in “ Output format setting ID_OUTPUT_FORMAT=0x05 ” section. 6.5 Continuous Ranging Mode TF-Luna will keep tracking the distance 500 times per second, but as the customized output frequency is lower, the output may take the average. For instance, if the output frequency is 100Hz as default, then the output values are the average (arithmetic mean) of 5 previous range data. Therefore, lower output frequency gives less time of the
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
averaging process as well as less fluctuation of the output. The highest output frequency that TF-Luna supports is 250Hz (output_frequency ≤ 250Hz), and it must be 500/n Hz (where n is an integer that is in the range [2, 500]). Thus, all supported values of output frequency are: 250Hz, 166Hz, 125Hz, 100Hz, …, 2Hz, 1Hz. User can change the output frequency using “ Output frequency ID_SAMPLE_FREQ=0x03 ”. 6.6 Trigger Mode
| Parameter | Value |
|---|---|
| TF-Luna enters trigger mode if the output frequency is set to 0 with “ | Output frequency |
| ID_SAMPLE_FREQ=0x03 | ”. In this mode, TF-Luna stops measuring and outputting unless |
| it is triggered by “ Trigger mode ID_SAMPLE_TRIG=0x04 | ” — in other words, TF-Luna |
measures and output once as soon as it receives the hexadecimal byte string 5A 04 04 00. 6.7 On/off Mode On/off mode is designed from those users who only need to detect the existence of an object. TF-Luna can start this mode using “ Enable/disable on-off mode ID_ON_OFF_MODE=0x3B ” and then shows result through pin 6. Figure 6 below shows how the mode works when a high level is set to represent an object is detected.
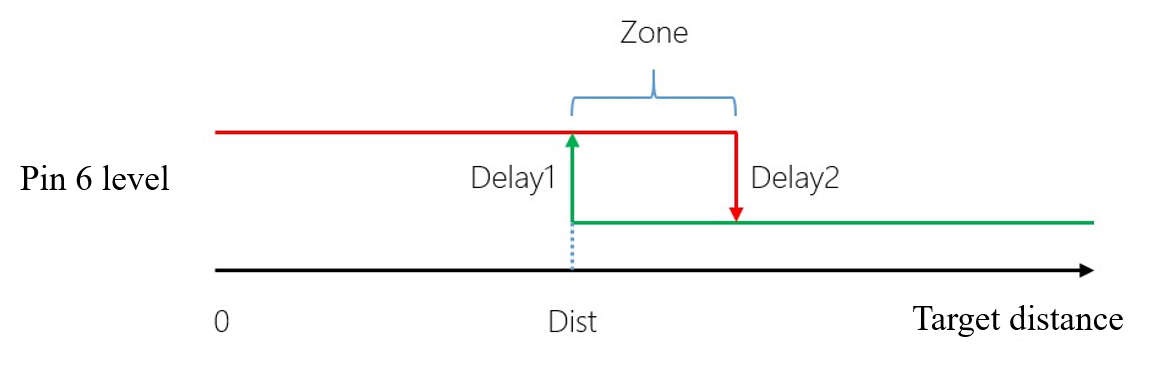
Figure 6 On/off mode that high level means closer
Zone value: If an object is detected closer than Dist, then Pin 6 outputs high-level, but only if an object is detected farther than Dist + Zone, then Pin 6 outputs low-level. When zone is set to 0, pin 6 may output up and down cause by fluctuation of the measuring when the real distance happens to be the same as Dist. That is why a proper zone value is needed to help avoid this situation by having a hysteretic interval. Delay is also supported to avoid inaccurate jumping output. Pin 6 changes its output depends on the Dist value condition and the time it lasts. Delay1(ms) and Delay2(ms) determine how long that approaching changes and leaving changes should wait after Dist value is already over the line. Note: Since the Dist value is set to 0 under factory setting when no object is detected and Amp is too low, then pin 6 may have false output in the on/off mode. Please follow the instructions in 6.8 Amp to set the over-threshold value greater than Dist + Zone to
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
avoid false output. 6.8 Amp Threshold The distance calculation may get false result if the Amp value is too low, so TF-Luna set the Dist value to dummy_dist(Default 0) when Amp is lower than amp_threshold (Default 100). If a user needs to change the Amp threshold value, please follow instructions in “ Amp threshold setting ID_AMP_THRESHOLD=0x22 ”. Note that the final Amp threshold in TF-Luna is 10 times the value you send to it. 6.9 Distance Limit TF-Luna has a default maximum and minimum distance output: [min, max] = [0cm, 900cm]. User can change the output limits using “ Distance limit setting ID_DIST_LIMIT=0x3A ”. Note: Any distance value lower than 20cm or greater than 800cm may be unreliable. 6.10 Power Saving Mode The power consumption of TF-Luna is determined by two factors: the light source driving current and the light-emitting duty cycle. TF-Luna adjusts the driving current of the light source adaptively to achieve the purpose of large dynamic range adapting to different distances and different reflectivity targets. When the signal strength is too high, it will automatically switch to low gear current work. On the contrary, when the signal strength is too low, it will automatically switch to high gear current work. The higher the current gear is, the greater the power consumption will be. Refer to " 6.5 Continuous Ranging ". In continuous ranging mode, TF-Luna always emits light with the highest duty cycle, which does not change with the output frequency. Therefore, when TF-Luna is in continuous working mode and the current gear is at the highest gear, the power consumption is the largest. When the power is supplied with 5V, the power consumption is about 350mW. The user can change TF-Luna's luminous duty cycle in two ways. The first is to use the command trigger mode. TF-Luna does not emit light when it does not receive a ranging command. At this time, the power consumption is about 42.5mW (5V power supply). The actual power consumption is determined by the frequency of the command trigger. Another way is to enable the low power consumption mode provided by TF-Luna. The internal working mechanism of this mode is the same as the command trigger mode, except that the trigger signal is automatically generated internally by TF-Luna. The user can set the TF-Luna to enter the low-power mode through the " Enable/disable Power saving mode (ECO) ID_LOW_CONSUMPTION=0x35 " instruction.
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
To ensure the internal working sequence of TF-Luna, the maximum output frequency of low power consumption mode is 10Hz. The following table lists the reference values of the average power consumption at different operating frequencies in the low power mode when the power supply is 5V. The actual power consumption may be affected by the ambient temperature or the supply voltage, and may differ from the reference value.
| Parameter | Value |
|---|---|
| Power saving frequency | Avg current(mA) Avg power (mW) |
| 1Hz | 8.85 44.25 |
| 2Hz | 9.2 46 |
| 3Hz | 9.55 47.75 |
| 4Hz | 9.9 49.5 |
| 5Hz | 10.25 51.25 |
| 6Hz | 10.6 53 |
| 7Hz | 10.95 54.75 |
| 8Hz | 11.3 56.5 |
| 9Hz | 11.65 58.25 |
| 10Hz | 12 60 |
6.11 Ultra-low Power Mode In order to further reduce power consumption, TF-Luna offers an Ultra-low Power Mode. In this mode, MCU enters sleep mode, and the standby power consumption of TF-Luna is about 1.5mW at this time. However, when MCU sleeps, it is not able to automatically awake as Low Power Mode is activated. Therefore, we need to change the voltage of Pin 2 to wake it up. 6.11.1 Ultra-low Power Mode with Serial Port Communication (1) Turn on Ultra-low Power Mode The command “ Ultra-low Power Mode ID_ ULTRA_LOW_POWER_MODE=0x58 ” is used to turn on Ultra-low Power Mode. TF-Luna will stop serial port outputting data once the command is delivered. However, it will not enter the mode immediately. Users should send “ Save current setting ID_SAVE_SETTINGS=0x11 ” to save current settings and then send “ System software restore ID_SOFT_RESET=0x02 ” to reset system. Later on, TF-Luna will enter the Ultra-low Power Mode. Since the settings have been saved, TF-Luna will enter directly into this mode on next boot-up. (2) Bring up Range-finding Users can wake up TF-Luna and make it perform range-finding once by sending a random byte to the serial port. TF-Luna will send back the range-finding result in a specific format, and then enter Ultra-low Power Mode once again. The following graph shows the case in which the baud rate is 115200 with 9-byte output format. The
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
awakening lasts about 8.5ms.
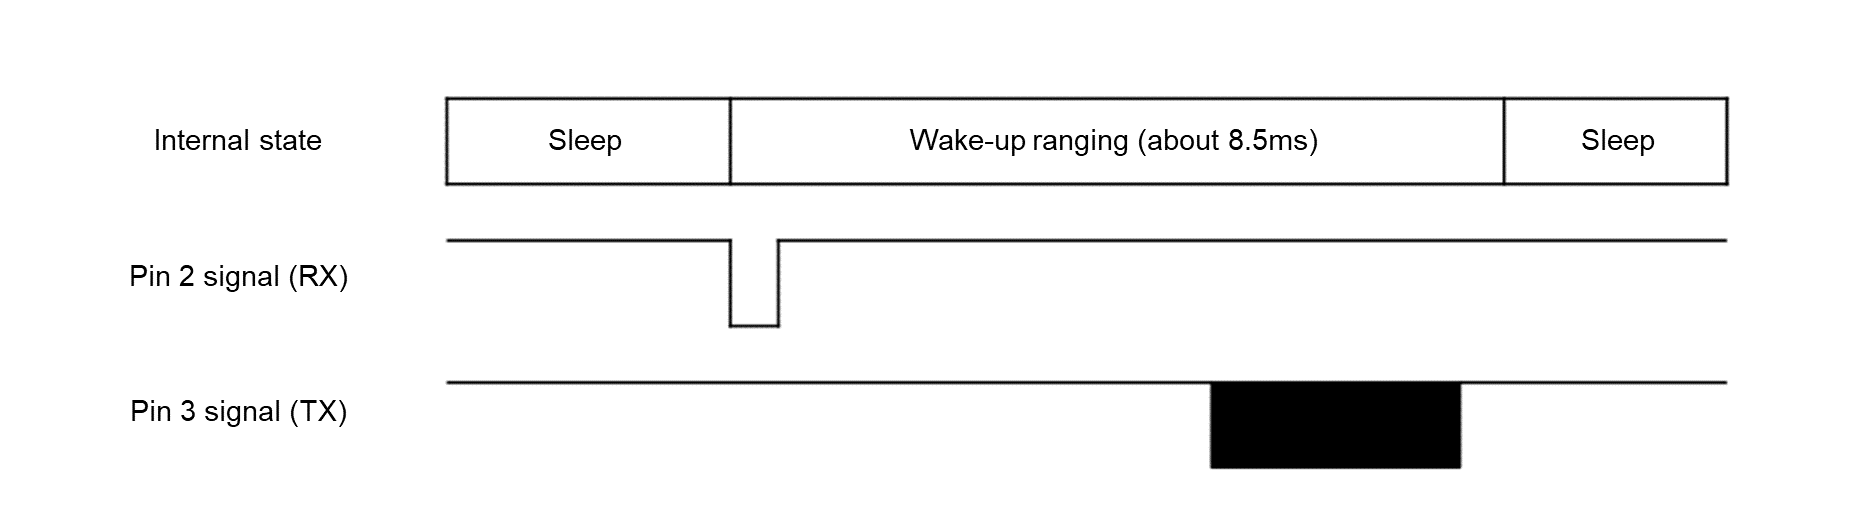
Figure 7 Time sequence of Ultra-low Power Mode with serial port communication
(3) Turn off Ultra-low Power Mode Users cannot exit the Ultra-low Power Mode directly, because the serial port communication module is disabled. TF-Luna can only receive serial port commands during short intervals when it is awake. Therefore, users need to continuously send the
| Parameter | Value |
|---|---|
| command “ Ultra-low Power Mode ID_ ULTRA_LOW_POWER_MODE=0x58 | ” to disable |
| the Ultra-low Power Mode untill TF-Luna responds. After that, users should send “ | Save |
| current setting ID_SAVE_SETTINGS=0x11 | ” command to save current settings. |
(4) Estimation of Power Consumption TF-Luna consumes 1.5mW during sleep and on average 260mW during awakening. The awakening will last about 8.5ms. Based on the information, it consumes on average 3.7mW if we wake it up every second and on average 1.72mW if we wake it up every ten seconds. 6.11.2 Ultra-low Power Mode with I2C communication (1) Turn on Ultra-low Power Mode In order to turn on and save Ultra-low Power Mode, users need to write three consecutive bytes [0x01, 0x01, 0x02] to the address 0x1F. (2) Bring up Range-finding Users can attempt reading any one of valid or invalid register addresses (which will not make us receive ACK from the slave device). In this way, TF-Luna will detect the change of voltage on Pin 2 and thus it will be awaken. TF-Luna will perform range-finding once upon each awakening, and update the result on the register. It will not fall back to sleep mode until the user performs a read-register operation.
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
Figure 8 Time sequence of Ultra-low Power Mode with I2C communication
(3) Turn off Ultra-low Power Mode Reading the register will make TF-Luna enter sleep mode once again, therefore, in order to turn off the Ultra-low Power Mode, users need to write three consecutive bytes [0x00, 0x01, 0x02] to the address 0x1F after the awakening. It should be done no sooner than 6ms after the awakening). (4) Estimation of Power Consumption TF-Luna consumes 1.5mW during sleep and on average 200mW during awakening. Range-finding in an awakening period takes about 12ms, and awaiting users ’ read-operation consumes about 42.2mW. Assuming it waits for 5ms, based on the information, it consumes on average 4.1mW if we wake it up every one second, and on average 1.76mW if we wake it up every ten seconds. 6.11.3 Caveats Users should not send any setup command in the Ultra-low Power Mode, because MCU will be in sleep so that it may not respond to users ’ command. In Ultra-low Power Mode, it is only allowed to bring up range-finding, or to turn off the mode. All other operations should be performed after the mode is turned off. 6.12 Single Frequency Mode TF-Luna obtains distance measurement from phase shift of the sinusoidal modulated laser light. The model is subjected to the “periodic distance” problem. The periodic distance for TF-Luna is 15 meters, when working in Single Frequency Mode. However, when the distance is beyond 15 meters, the measured value starts from zero again. Assuming there is a highly reflective object at 16 meters; TF-Luna may mistake it as at 1 meter. In order to extend the periodic distance, TF-Luna sets the default work mode to Dual Frequency Mode. The periodic distance in such a mode is over 65 meters, far wider than the sensor ’ s measuring range. In this way, the “ overshoot ” problem is addressed. However, in Dual Frequency Mode, the range-finding algorithm requires higher
FUNCTIONAL DESCRIPTIONS AND CONFIGURATION
stability on sensor data. When the signal is weak (AMP lower than 100), the low data stability produces errors in the range algorithm, and thus yields anomalies in output range values. The error can reach tens of meters. In some application scenarios, the target reflection rate is low so that AMPs lower than 100 are needed. In this case, users can set TF-Luna to Single Frequency Mode. In Single Frequency Mode, when AMP is lower than 100, the stability of range data is low. Even so, it is not allowed to have significant anomalies on data values. Meanwhile, users should make sure their application scenarios are not subjected to the overshoot problems. 6.13 Additional notes Please check Appendix II Serial communication protocol for more options, such as version ID report, system software restore, baud rate configuration, etc.
QUICK TEST GUIDE
7 QUICK TEST GUIDE
7.1 Required tools for testing
TF-Luna Data cable TTL to USB USB cable PC PC
convertor software
7.2 Steps 1 Download and install the latest test software Please visit our official website (https://ai.benewake.com/zh/products/tf-luna/) and download the test software of TF-Luna. Note: Please turn off any anti-virus software before uncompressing the PC software. Some anti-virus software may regard the ‘.exe’ file as virus. Also, released versions are only running on windows systems currently. 2 Connecting hardware and cables
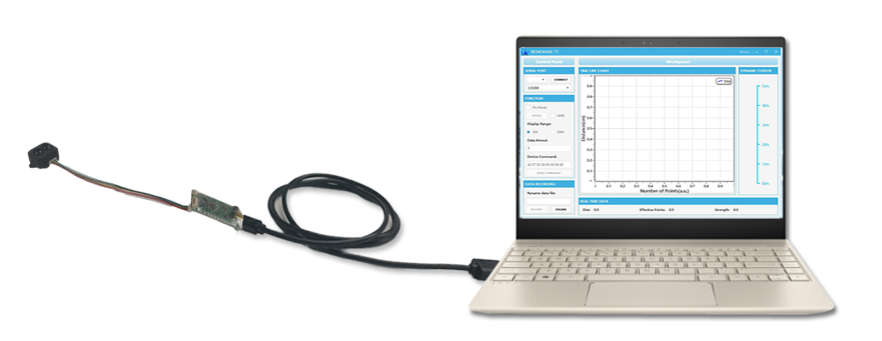
Figure 9 Schematic Diagram of Correct Connection
Please connect TF-Luna, TTL-USB converter, and USB cable properly as shown in Figure
9. Please check if there is any loose connection, and then plug the USB cable into your PC. 3 Open your test software and check data output Open the PC software and select “ ① TF-Luna ” and select automatically recognized occupied serial port (in this case “② COM9”) as shown in Figure 10.
QUICK TEST GUIDE
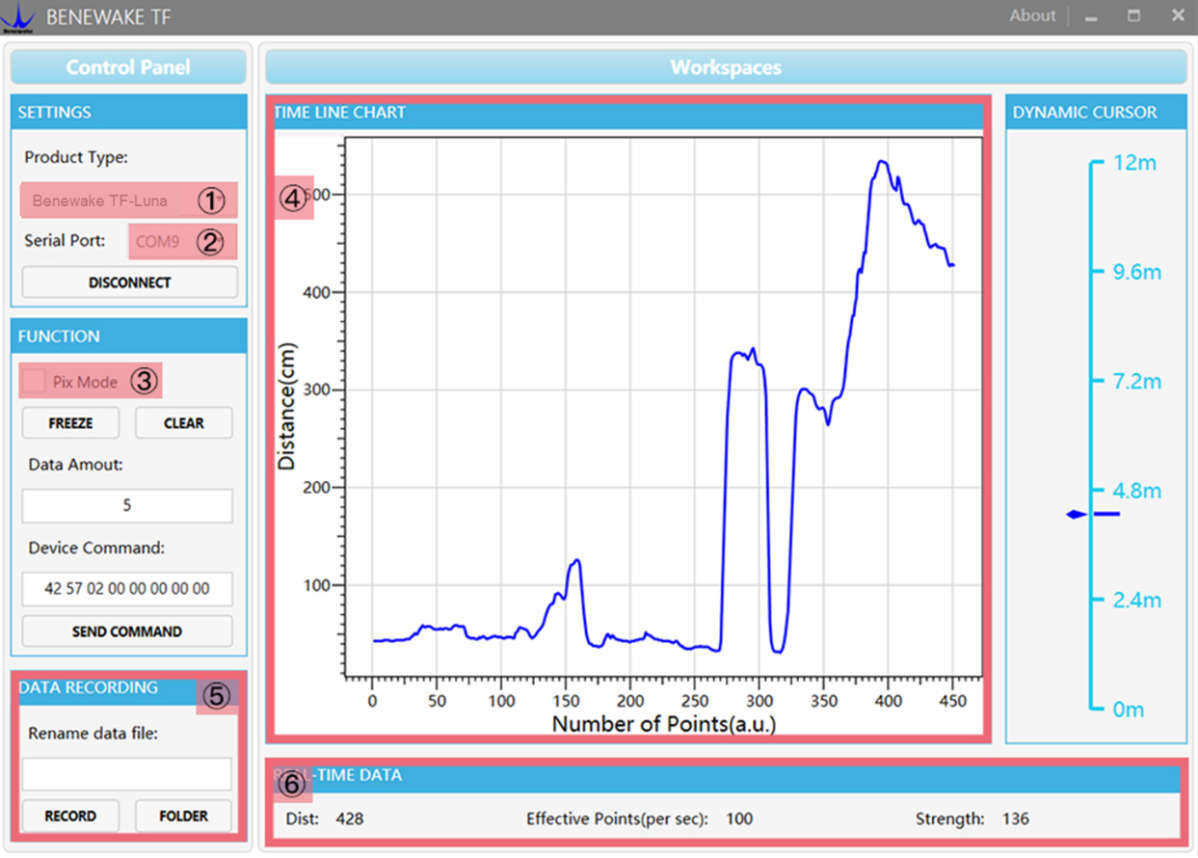
Figure 10 PC software Interface and Display
Now click the “CONNECT” button, and a continuous images of the output data will be displayed in area “ ④ TIME LINE CHART ” on the right if everything is connected successfully. The real-time data of the Current measure distance (Dist), effective data points per second (Effective Points) and signal strength (Strength) will be displayed in area “⑥ REAL TIME DATA” below as well.
Notes:
a) If nothing is displayed in area “ ④ TIME LINE CHART ” , please check the wire connection and sequence. A red LED indicator inside the transmitting lens at front will light up when TF-Luna is power-on. b) Please select “③Pix Mode” before switching TF-Luna’s outputs to Pixhawk format to avoid abnormal data display in the “④TIME LINE CHART” area. Note that selecting Pix Mode will automatically set the unit of distance to meters. c) Since TF-Luna does not pass unit information and the software always uses centimeters as distance unit, the distance unit displayed in the chart remains the same as centimeter even if TF-Luna output in millimeter. For instance, suppose the actual measurement is one meter and the distance value from TF-Luna is 1000 mm, then the value read by the PC software is 1000. Thus, the software will display 1000 with unit cm.
FIRMWARE UPGRADE
8 FIRMWARE UPGRADE
TF-Luna allows upgrading firmware remotely when current firmware no longer supports users ’ new requirements. Please contact us for the additional remote upgrading software if any relevant firmware upgrades are available on Benewake official website.
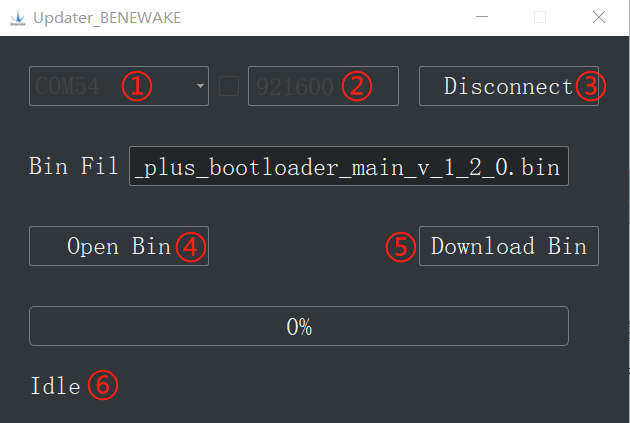
Figure 11 Firmware Upgrade PC software of TF-Luna
The tools for an upgrade are mostly the same as those in the Quick Test Guide, including a TTL-USB convertor to connect TF-Luna with PC. Open the Updater.exe after connecting TF-Luna to your PC, and then select the correct port and baud rate, “①COM8” and “② 115200” in this case. Click “④ Open Bin” to choose the updating firmware, then the file directory will be displayed in the textbox above. Finally, click “ ⑤ Download Bin ” to start upgrading and the upgrading information will show up in “⑥”. Note: The full directory of the firmware files must use English letters only.
APPENDIX I SERIAL PORT OUTPUT FORMAT
APPENDIX I SERIAL PORT OUTPUT
FORMAT
1. 9-byte/cm (Default) This format is supported for any firmware after Ver. 0.0.5
| Parameter | Value |
|---|---|
| Byte 0 1 | 2 3 4 5 6 7 8 |
| Descriptio 0x5 0x5 | Dist_ Dist_ Amp_ Amp_ Temp_ Temp_ Check_su |
| n 9 9 | L H L H L H m |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Temp: Celsius temperature = Temp / 8 - 256℃
2. PIX This format is supported for any firmware after Ver. 0.0.5 “X.YZ\r\n” is a sample ASCII string and only keep two significant digits in meter where “X.YZ” is the result.
3. 9-byte/mm This format is supported for any firmware after Ver. 0.0.5
| Parameter | Value |
|---|---|
| byte 0 1 | 2 3 4 5 6 7 8 |
| Descriptio 0x5 0x5 | Dist_ Dist_ Amp_ Amp_ Temp_ Temp_ Check_su |
| n 9 9 | L H L H L H m |
Dist: mm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Temp: Celsius temperature = Temp / 8 - 256℃
4. 32-byte with timestamp This format is supported for any firmware after Ver. 0.0.5
| Parameter | Value |
|---|---|
| byte 0 | 1 2 3 4 5 6-9 10 |
| Descriptio 0x59 0x59 | Dist_ Dist_ Amp_ Amp_ Timestam Check_su |
| n | L H L H p m |
Dist: cm
APPENDIX I SERIAL PORT OUTPUT FORMAT
Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
5. ID-0 output This format is supported for any firmware after Ver. 0.0.5
| Parameter | Value |
|---|---|
| byte 0 1 | 2 3 4 5 6 7-10 11 |
| Descriptio 0x5 Le | 0x0 Dist_ Dist_ Amp_ Amp_ Timestam Check_su |
| n A n | 0 L H L H p m |
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
6. 8-byte/cm This format is supported for any firmware after Ver. 0.0.5
byte 0 1 2 3 4-7 Description Dist_L Dist_H Amp_L Amp_H Timestamp
Dist: cm Amp: Signal strength indicator. Dist value is unreliable when Amp < 100 or Amp = 65535 (Overexposure) Timestamp: Timestamp (ms) is in small-end format
7. Output with Device ID This format is supported for any firmware after Ver. 3.0.8
| Parameter | Value |
|---|---|
| byte 0 1 | 2 3 4 5 6 7-10 11 12 |
| Descri 0x5 0x0 0x0 | Dist_ Dist_ Amp_ Amp_ Timesta Dev_ Check_su |
| ption A D | 0 L H L H mp Id m |
Dist: cm Amp: Signal strength, if AMP is lower than 100, the range value is considered not reliable. Overexposure value is 65535 Timestamp:Timestamp (ms) is in little-endian format Dev_Id: device ID, same as the address of I2C slave device
Appendix II Serial communication protocol
Appendix II Serial communication
protocol
1. Version information ID_GET_VERSION=0x01 This format is supported for any firmware after Ver. 0.0.5 Downward:
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward:
byte 0 1 2 3~5 Len-1 Description Head(0x5A) Len ID *Version Check_sum
*Version: For instance, if the third, fourth, and fifth bytes are 112, 50, 9, then the version is 9.50.112 Sample instruction: [5A 04 01 00]
2. System software restore
ID_SOFT_RESET=0x02 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID *Status Check_sum *Status: 0 (success), otherwise (fail) Note: Any change without “save current setting” instruction will not be saved and will restore to original setting. Sample instruction: [5A 04 02 00]
3. Output frequency ID_SAMPLE_FREQ=0x03 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 3~4 Len-1
Appendix II Serial communication protocol
Description Head(0x5A) Len ID Freq Check_sum Default 100 Freq: Working frequency if Freq > 0, and Trigger mode if Freq = 0. Upward
byte 0 1 2 3~4 Len-1 Description Head(0x5A) Len ID Freq Check_sum
Freq: The current working frequency of the LiDAR Sample instruction: 10Hz [5A 06 03 0A 00 00] 250Hz [5A 06 03 FA 00 00]
4. Trigger mode ID_SAMPLE_TRIG=0x04 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward Data frame Sample instruction: [5A 04 04 00]
5. Output format setting
ID_OUTPUT_FORMAT=0x05 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Format Check_sum |
| Default | 0x01 |
Format: 0x01 = 9-byte/cm 0x02 = PIX 0x06 = 9-byte/mm 0x07 = 32-byte with timestamp 0x08 = ID-0 0x09 = 8-byte/cm 0x0A = Output with device ID Upward
byte 0 1 2 3 Len-1
Appendix II Serial communication protocol
Description Head(0x5A) Len ID Format Check_sum
Format: TF-Luna’s current output format setting Example: [5A 05 05 02 00] means PIX
6. Baud rate setting ID_BAUD_RATE=0x06 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3~6 Len-1 |
| Description | Head(0x5A) Len ID Baud rate Check_sum |
| Default | 115200 |
Upward
byte 0 1 2 3~6 Len-1 Description Head(0x5A) Len ID Baud rate Check_sum
Baud rate: TF-Luna’s current baud rate. Note: Only baud rate in [9600, 921600] are supported. Example: 9600 [5A 08 06 80 25 00 00 00] 19200 [5A 08 06 00 4B 00 00 00] 38400 [5A 08 06 00 96 00 00 00] 57600 [5A 08 06 00 E1 00 00 00] 115200 [5A 08 06 00 C2 01 00 00] 230400 [5A 08 06 00 84 03 00 00] 460800 [5A 08 06 00 08 07 00 00] 921600 [5A 08 06 00 10 0E 00 00]
7. Enable/disable output ID_OUTPUT_EN=0x07 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Enable Check_sum |
| Default | 1 |
Enable: 0 to disable, 1 to enable. Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Example: Enable output [5A 05 07 01 00] Disable output [5A 05 07 00 00]
Appendix II Serial communication protocol
8. Enable/disable checksum comparison
ID_FRAME_CHECKSUM_EN=0x08 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Enable Check_sum |
| Default | 0 |
Enable: 0 to disable, 1 to enable. Note: Even if the Downward data checksum comparison is disabled, the valid checksum is still included in the upward data frame Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Example: Enable checksum comparison [5A 05 08 01 00] Disable checksum comparison [5A 05 08 00 67]
9. I 2 C slave machine address configuration
ID_I 2 C_SLAVE_ADDR=0x0B This format is supported for any firmware after Ver. 1.0.0 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID I2c_slave_addr Check_sum |
| Default | 0x10 |
I 2 c_slave_addr: range [0x08, 0x77] Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID I2c_slave_addr Check_sum
Example: Change to 0x20 [5A 05 0B 20 00]
10. Restore default setting
ID_RESTORE_DEFAULT=0x10 This format is supported for any firmware after Ver. 0.0.5 Downward
Appendix II Serial communication protocol
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Status Check_sum
Status: 0 for success, otherwise for errors Example: Restore default setting [5A 04 10 00]
11. Save current setting
ID_SAVE_SETTINGS=0x11 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Status Check_sum
Status: 0 for success, otherwise for errors Example: [5A 04 11 00]
12. Output product bar code
ID_READ_MANU_BIN=0x12 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward
byte 0 1 2 3-16 Len-1 Description Head(0x5A) Len ID Bin Check_sum
Bin: 14 byte product bar code Example: Send [5A 04 12 00] Receive: U0900018010001, then the code is from the third byte to the sixteenth: 0x55 0x30 0x39 0x30 0x30 0x30 0x31 0x38 0x30 0x31 0x30 0x30 0x30 0x31
Appendix II Serial communication protocol
13. Get full-length version number
ID_GET_FULL_VERSION=0x14 This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward byte 0 1 2 3-1 1 12-1 2 21-2 2 24-2 2 27-28 Len-
0 1 9 0 2 3 5 6 1
Majo Mino
| Parameter | Value |
|---|---|
| Hea | r r Revisi Chec |
| Descrip d Le | I Na ‘.’ Bran ‘.’ versi ‘.’ versi ‘.’ on k_su |
| tion (0x5 n | D me ch on on versio m |
| A) | No. No. n No. |
Example: [5A 04 14 00]
14. Amp threshold setting
ID_AMP_THRESHOLD=0x22 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte 0 | 1 2 3 4-5 Len-1 |
| Description Head(0x5A) | Len ID Amp_Threshold Dummy_Dist Check_sum |
| Default | 10 0 |
Amp_Threshold: When Amp < Amp_Threshold * 10, then output Dummy_Dist instead of the result of calculation Dummy_Dist: The output distance when Amp is too low. Upward byte 0 1 2 3 4-5 Len-1 Description Head(0x5A) Len ID Amp_Threshold Dummy_Dist Check_sum Example: To output 500 cm when Amp < 300 [5A 07 22 1E F4 01 00]
Appendix II Serial communication protocol
15. Switch between Single Frequency and
Dual Frequency ID_ DEALIAS_EN =0x29 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Enable Check_sum |
| Default | 1 |
Enable: 1(Dual Frequency Mode)0(Single Frequency Mode) Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Example: Dual Frequency Mode [5A 05 29 01 00] Single Frequency Mode [5A 05 29 00 00]
16. Timestamp synchronization
ID_TIMESTAMP_SYNC =0x31 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3-6 Len-1 |
| Description | Head(0x5A) Len ID Std Check_sum |
| Default | 0 |
Std: The current std timestamp specified Example: To set timestamp to 1000ms [5A 08 31 E8 03 00 00 00]
17. Enable/disable Power saving mode (ECO)
ID_LOW_CONSUMPTION=0x35 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3-4 Len-1 |
| Description | Head(0x5A) Len ID Sample_rate Check_sum |
| Default | 0 |
Sample_rate: Work frequency if Sample_rate is positive (0 to disable power saving)
Appendix II Serial communication protocol
Upward
byte 0 1 2 3-4 Len-1 Description Head(0x5A) Len ID Sample_rate Check_sum
Example: Enable power saving mode and measure at 10Hz frequency [5A 06 35 0A 00 00]
18. Filter Setup ID_FILTER_BIT_MAP=0x39 This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Filter_bit_map Check_sum |
| Default | 0x03 |
Filter_bit_map: Filter setup: 0 to disable, 1 to enable. Bit0 – Kalman Filter Bit1 – Median Filter Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Filter_bit_map Check_sum
Example: Filter off [5A 05 39 00 00] Filter on [5A 05 39 03 00]
19. Distance limit setting ID_DIST_LIMIT=0x3A This format is supported for any firmware after Ver. 0.0.5 Downward
| Parameter | Value |
|---|---|
| byte | 0 1 2 3-4 5-6 7 Len-1 |
| Description Head(0x5A) | Len ID Dist_min Dist_max Silence Check_sum |
| Default | 0 900 0 |
Dist_min: minimum distance output in centimeters. Dist_max: maximum distance output in centimeters. Silence: No output when the distance is out of range if silence = 1. Output limit when out of range if silence = 0 Upward byte 0 1 2 3-4 5-6 7 Len-1 Description Head(0x5A) Len ID Dist_min Dist_max Silence Check_sum Example: Output limit when out of range with the minimum set to be 20cm and the maximum set to be 500cm
Appendix II Serial communication protocol
[5A 09 3A 14 00 F4 01 00 00]
20. Enable/disable on-off mode
ID_ON_OFF_MODE=0x3B This format is supported for any firmware after Ver. 1.0.0 Downward
| Parameter | Value |
|---|---|
| byte 0 | 1 2 3 4-5 6-7 8-9 10-11 Len-1 |
| Descriptio Head(0x5A | Le I Mod Dis Zon Delay Delay Check_su |
| n ) | n D e t e 1 2 m |
| Default | 0 0 0 0 0 |
Mode: 0 (Normal output), 1 (On-off mode with high level output when closer) , 2 (On-off mode with low level output when closer) Dist: critical dist value (the closer one) in centimeters. Zone: Zone size in centimeters Delay1: Delay time 1 in millisecond. Pin 6 switch level only if the distance detected is less than Dist and the situation last for Delay1 long. Delay2: Delay time 2 in millisecond. Pin 6 switch level only if the distance detected is more than Dist + Zone and the situation last for Delay2 long. Example: Enable on-off mode with high level output when closer, and set Dist = 200cm, Zone=10cm, Delay1 = Delay2 = 1000ms: [5A 0D 3B 01 CB 00 0A 00 E8 03 E8 03 00]
21. Read config by id
ID_GET_CONFIG_PARA=0x3F This format is supported for any firmware after Ver. 0.0.5 Downward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Id Check_sum
Id: The same as we mentioned above. Upward: The same format of relevant Id. Example: Read output frequency [5A 05 3F 03 00]
22. Ultra-low Power Mode ID_
ULTRA_LOW_POWER_MODE=0x58 This format is supported for any firmware after Ver. 3.0.7
Appendix II Serial communication protocol
Downward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Enable:0 to disable, 1 to enable. Upward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Example: Turn on Ultra-low Power Mode [5A 05 58 01 00] Turn off Ultra-low Power Mode [5A 05 58 00 00]. Since there is a time period in an Ultra-low Power Mode awakening phase, the turn-off command should be sent multiple times, e.g. [5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00 5A 05 58 00 00]
23. Frequency Calibration
ID_FREQ_CNT_CALIB=0x59 This format is supported for any firmware after Ver. 3.0.7 Downward
byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Cmd Check_sum
Cmd : 1 (Execute frequency calibration, which takes about two seconds), 2 (Read frequency calibration parameters) Upward
byte 0 1 2 3-4 Len-1 Description Head(0x5A) Len ID Calib_freq_cnt Check_sum
Calib_freq_cnt : For frequency calibration parameters, a non-zero value indicates the completion of calibration Example: Execute frequency calibration [5A 05 59 01 00] Read frequency calibration parameters [5A 05 59 02 00]
Appendix III I2C REGISTER TABLE
Appendix III I 2 C REGISTER TABLE
Address R/W Name Initial Description
Value
| Parameter | Value |
|---|---|
| 0x00 R | DIST_LOW -- cm |
| 0x01 R | DIST_HIGH -- |
| 0x02 R | AMP_LOW -- |
| 0x03 R | AMP_HIGH -- |
| 0x04 R | TEMP_LOW -- Unit: 0.01 Celsius |
| 0x05 R | TEMP_HIGH -- |
| 0x06 R | TICK_LOW -- Timestamp |
| 0x07 R | TICK_HIGH -- |
| 0x08 R | ERROR_LOW -- |
| 0x09 R | ERROR_HIGH -- |
| 0x0A R | VERSION_REVISION -- |
| 0x0B R | VERSION_MINOR -- |
| 0x0C R | VERSION_MAJOR -- |
| 0x0D-0x0F | -- Hold |
Production code in 14
0x10-0x1D R SN -- bytes ASCI code (0x10 is
the first byte)
0x1E -- Hold
0x00: Normal
0x1F W ULTRA_LOW_POWER -- 0x01: Ultra-low power
mode
0x20 W SAVE -- Write 0x01 to save
current setting
0x21 W SHUTDOWN/REBOOT -- Write 0x02 to reboot 0x22 W/R SLAVE_ADDR 0x10 Range: [0x08, 0x77]
0x00: Continuous
0x23 W/R MODE 0x00 ranging mode
0x01: Trigger mode
0x24 W TRIG_ONE_SHOT -- 0x01: Trigger once (only
on trigger mode)
0x25 W/R ENABLE 0x01 0x00: Turn off LiDAR
Appendix III I2C REGISTER TABLE
0x01: Turn on LiDAR
0x26 W/R FPS_LOW 0x64 0x27 W/R FPS_HIGH 0x00
0x00: Normal
0x28 W/R LOW_POWER 0x00 0x01: Power saving
mode
0x29 W RESTORE_FACTORY_DEFAULTS -- Write 0x01 to restore
factory default settings
| Parameter | Value |
|---|---|
| 0x2A W/R | AMP_THR_LOW 0x64 Amp threshold value |
| 0x2B W/R | AMP_THR_HIGH 0x00 |
| 0x2C W/R | DUMMY_DIST_LOW 0x00 Dummy dist value |
| 0x2D W/R | DUMMY_DIST_HIGH 0x00 |
Minimum dist in mm, but
0x2E W/R MIN_DIST_LOW 0x00 not working on
DUMMY_DIST
0x2F W/R MIN_DIST_HIGH 0x00
Maximum dist in mm, but
0x30 W/R MAX_DIST_LOW 0x20 not working on
DUMMY_DIST
| Parameter | Value |
|---|---|
| 0x31 W/R | MAX_DIST_HIGH 0x03 |
| 0x32-0x3B | -- Hold |
| 0x3C-0x3F R | SIGNATURE -- ‘L’ ’U’ ‘N’ ‘A’ |