
技术资料
tf-luna 技术资料
Benewake TF-Luna-UW
Benewake TF-Luna-UW
s
Datasheet
TF-Luna-UW is a single-point Time-of-Flight (ToF) LiDAR, using an 850nm infrared light source and a unique optical and electrical design for stable, precise, and highly sensitive distance measurement. Highly adaptable to various environments and targets, it's ideal for outdoor pool robots, even in direct sunlight. Advantages: Compact size, high accuracy, low power consumption, and algorithms optimized for underwater applications. Applications: Pool edge mapping, underwater obstacle avoidance, and pool step detection.
Technical Specifications
Underwater Measurement Performance
| Parameter | Value |
|---|---|
| Detection range | 10cm~55cm ① ,in clear water |
| Accuracy | <±3 cm ① |
| Repeatability | < ±1 cm ① |
| Distance resolution | 1cm |
| Default frame rate ② | 100Hz |
Optical Parameters
| Parameter | Value |
|---|---|
| Light source | VCSEL |
| Central wavelength | 850nm |
| FoV of laser emission ③ | 2° |
| Eye safety | Class 1 Eye-safe[EN60825] |
Mechanical/Electrical
| Parameter | Value |
|---|---|
| Power supply | DC 3.7V~5.2V |
| Average power consumption | ≤ 70mA |
| Power consumption | ≤ 0.35W |
| Peak current | 150mA |
| Storage temperature | -20 ℃ ~75 ℃ |
| Communication level | LVTTL ( 3.3V ) |
| Dimensions | 35mm*21.25mm*13.5mm |
| Weight | <5g |
Chassis material PC/ABS Cable length 10cm
Communication Protocol ④
| Parameter | Value |
|---|---|
| UART | I2C |
| Baud rate 115200 (Adjustable) | Maximum transfer rate 400kbps |
| Data bit 8 | Master-follower mode Follower mode |
| Stop bit 1 | Default address 0x10 |
| Parity None | Address range 0x01~0x7F |
Dimensions (Unit: mm)
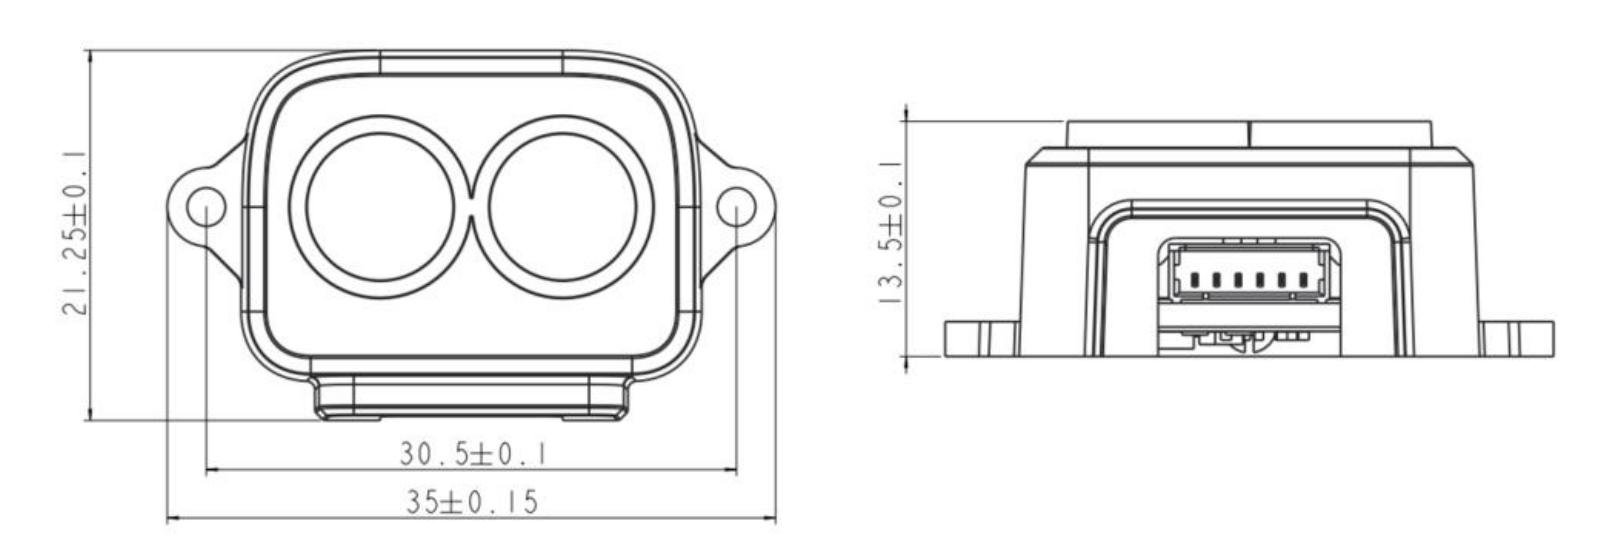
Notes to the specifications:
① reflectivity of 50% at 25°C. Results may vary under different conditions. The measured parameters is under indoor, clear water conditions with a target simulating a common tile ② Supports up to 250 Hz; configurable frame rates are 500/n Hz, where n is an integer ≥ 2 (e.g., 250, 167, 125, 100 Hz). The factory default is 100 Hz. ③ This angle is a theoretical value; some deviation from the actual angle may occur. UART and I2C use different pins and require a command to switch communication protocols. See the user ④ manual for details.
Declaration: The copyright of this specification belongs to © Benewake (Beijing) Co., Ltd. is not allowed to copy, modify, delete or translate the content of this specification without written permission from Benewake. Our product is constantly improving and updating, so the specifications of TF-Luna-UW product may change. Please refer to the latest version released by Benewake.