
Technical documents
TF-NOVA User Manual
TF-NOVA User Manual
TF-NOVA User Manual
Preface
This user manual contains the introduction, use and maintenance of TF-NOVA LiDAR. Please read this manual carefully before formal use, and strictly follow the steps described in the manual during use to avoid product damage, property loss, personal injury or/and violation of product warranty terms. If you encounter problems that cannot be solved during use, please contact Benewake staff for assistance. Contact Details Official website: https://ai.benewake.com/en/products/tf-nova/ Contact number: 400-880-9610 For technical questions, please contact: support@benewake.com For sales inquiries or to request brochure, please contact: bw@benewake.com Headquarter Address Benewake (Beijing) Co., Ltd. 3rd Floor, Haiguo Jiaye Sci-Tech Park, Haidian District, Beijing, China Copyright Notice This User Manual is copyright © of Benewake. Please do not modify, delete or translate the description of this manual contents without the official written permission from Benewake. Disclaimer The TF-NOVA product is constantly being improved, and its specifications and parameters will undergo iterative changes. Please refer to the official website for latest version.
Contents
1 Laser Safety Information............................................................................................................... 1 2 Installation and Maintenance.....................................................................................................1 3 Product Overview............................................................................................................................ 1
| Parameter | Value |
|---|---|
| 3.1 Measuring Principle | ..................................................................................................................1 |
| 3.2 Technical Specifications | ...................................................................................................... 2 |
| 3.3 Structural Appearance | ......................................................................................................... 3 |
3.4 FoV............................................................................................................................................... 4 4 Device Installation......................................................................................................................... 4 4.1 Mechanical Installation.........................................................................................................4 4.2 Connector................................................................................................................................. 4
| Parameter | Value |
|---|---|
| 5 Communication Protocol and Data Format | ........................................................................ 6 |
| 5.1 Serial Communication | ............................................................................................................6 |
| 5.2 IIC Communication | .................................................................................................................7 |
5.3 On/off Mode............................................................................................................................. 7
| Parameter | Value |
|---|---|
| 5.4 Serial communication commands | ....................................................................................8 |
| 5.4.1 Version information ID_GET_VERSION=0x01 | ......................................................... 9 |
| 5.4.2 System software restore ID_SOFT_RESET=0x02 | .................................................9 |
| 5.4.3 Output frequency ID_SAMPLE_FREQ=0x03 | ........................................................ 10 |
| 5.4.4 Output format setting ID_OUTPUT_FORMAT=0x05 | ........................................ 10 |
| 5.4.5 Baud rate setting ID_BAUD_RATE=0x06 | ..............................................................10 |
| 5.4.6 Enable/disable output ID_OUTPUT_EN=0x07 | .....................................................11 |
| 5.4.7 Enable/disable checksum compariso ID_FRAME_CHECKSUM_EN=0x08 | .11 |
| 5.4.8 Communication interface settings ID_IF_PROTOCOL=0x0A | ....................... 12 |
| 5.4.9 IIC slave machine address configuration ID_IIC_SLAVE_ADDR=0x0B | ......13 |
| 5.4.10 Restore default setting ID_RESTORE_DEFAULT=0x10 | ................................... 13 |
| 5.4.11 Save current setting ID_SAVE_SETTINGS=0x11 | ..................................................13 |
| 5.4.12 Distance limit setting range ID_DIST_RANGE=0x3A | ...................................... 14 |
5.4.13 Enable/disable on-off mode ID_ON_OFF_MODE=0x3B.............................. 14 Appendix IIC REGISTER TABLE.................................................................................................15
1 Laser Safety Information
The LiDAR contains IR and visible laser spots. IR laser: Wavelength 905nm; Class 1 according to IEC 60825-1:2014, EN 60825-1:2014+A11:2021.
CAUTION! Use of controls, adjustments or performance of procedures other than those specified herein may result in hazardous radiation exposure.
2 Installation and Maintenance
CAUTION! This laser product is classified as Class 1 during operational procedures. When the ranging feature is activated, the laser emitter of the LiDAR module may emit laser radiation, therefore, the LiDAR should NOT be aimed at humans and animals to ensure safety. This product is designed and calibrated for installation with exposed lenses. If a protective window needs to be added in front of the lens, it is necessary to ensure the use of materials with high transmission at 905nm wavelength and anti- reflective coating. Avoid the presence of smoke and fog in the detection field. Avoid condensation. Avoid direct exposure to moisture and water. Do not use rough fabric or dirty towels or aggressive products to clean the laser lenses. Do not use a supply voltage higher than the maximum required in the specifications to power the product. Clean the laser lenses with compressed air. When needed, wipe the laser lenses only with a soft, clean microfiber cloth. Make sure the sensor is securely mounted to prevent false readings or damage. Only trained and qualified personnel may install, setup and repair the LiDAR.
3 Product Overview
This chapter mainly introduces the measuring principle, technical specifications, structural description, equipment coordinates and field of view distribution of the TF-NOVA LiDAR. 3.1 Measuring Principle TF-NOVA is a typical Pulse Time of Flight (PToF) sensor. TF-NOVA emits a narrow pulse laser, which is collimated by the transmitting lens, which enters the receiving system after being reflected by the measured target and is focused on the detector by the receiving lens. The time between the transmitted signal and the received signal is calculated through the circuit amplification and filtering, and the distance between TF-NOVA and the measured target can be calculated through the speed of light.
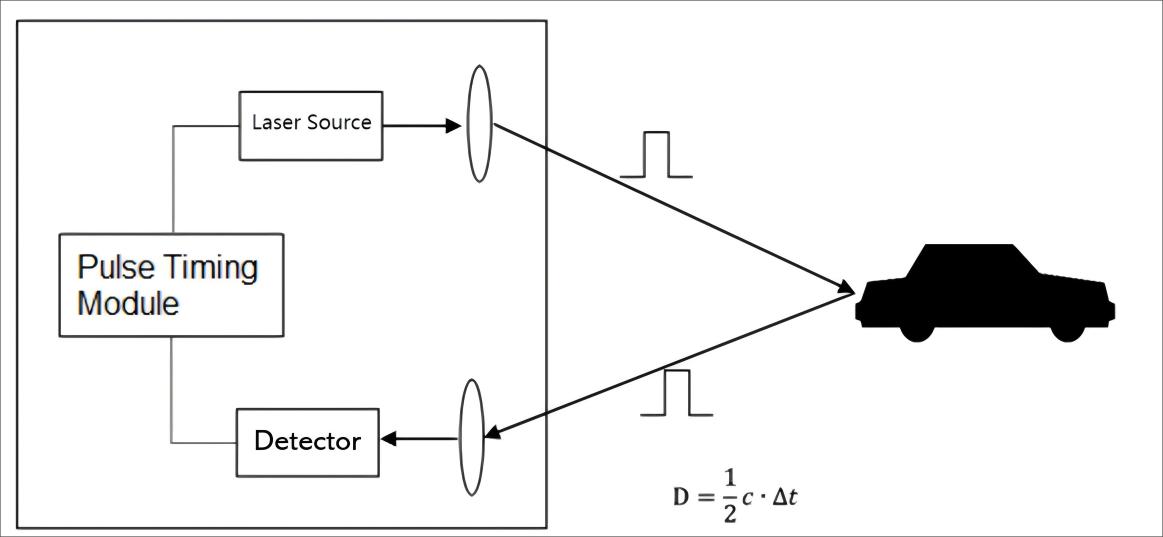
Figure. 1: Pulsed time of flight
3.2 Technical Specifications
Table. 1: Specification
Measurement Performance
≥14m @90%reflectivity, 0Klux ≥13m @10% reflectivity, 0Klux
Detection range ① ≥7m @90% reflectivity, 100Klux
≥4m @10% reflectivity, 100Klux
| Parameter | Value |
|---|---|
| Blind zone ② | ≤ 0.1m |
| Accuracy ② | ± 5cm @ 0.1-4m |
| Repeatability ② | < 1cm (1 sigma) @ 0.1-4m |
| Distance resolution | 1cm |
| Default frame rate | Default 100Hz, 1-900Hz customizable |
Optical Parameters
| Parameter | Value |
|---|---|
| Light source | VCSEL |
| Central wavelength | 905nm |
| FoV of laser emission ③ | Typ. 14°×1° |
| Eye safety | Class 1 Eye-safe[EN60825] |
Mechanical/Electrical
| Parameter | Value |
|---|---|
| Average power consumption ④ | < 500mW |
| peak current when starting ④ | < 850mA |
| Start-up time | < 1s |
| Power supply | DC 5±5%V |
| Operating temperature | -25 ℃ ~ +70 ℃ |
| Storage temperature | -30 ℃ ~ +80 ℃ |
| Dimensions | TYP. 26.5x 21.05 x 12.0mm ³ |
| Weight | <5g |
| Connector | 1.25mm-5P |
| Protection Level | N.A. |
| Front window protection level | IP65 |
| Cable length | 10cm |
Communication Protocol
Communication Interface UART, IIC, I/O Baud rate Default 115200
| Parameter | Value |
|---|---|
| Data bit | 8 |
| Stop bit | 1 |
| Parity | None |
Dimensions (Unit: mm)
NOTICE ① at 25 The measurement range is measured when all light spots are placed on the target board,. ② The parameter is measured at 25 ℃ ℃, 0Klux, when all the light spots are placed on the target board with a reflectivity of 10%. ③ This angle is the design divergence angle of the laser spot. The actual field of view angle that can trigger distance measurement depends on specific conditions such as the measured object and background. Please confirm according to the specific application. 3.3 Structural Appearance ④ Measured at 25 ℃, changes in conditions may cause variations in the measurement results.
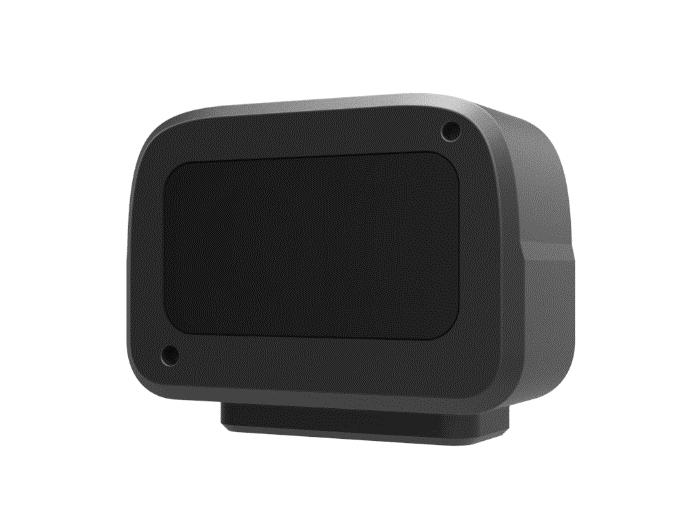
The overall appearance of the LiDAR is as shown in the figure below:
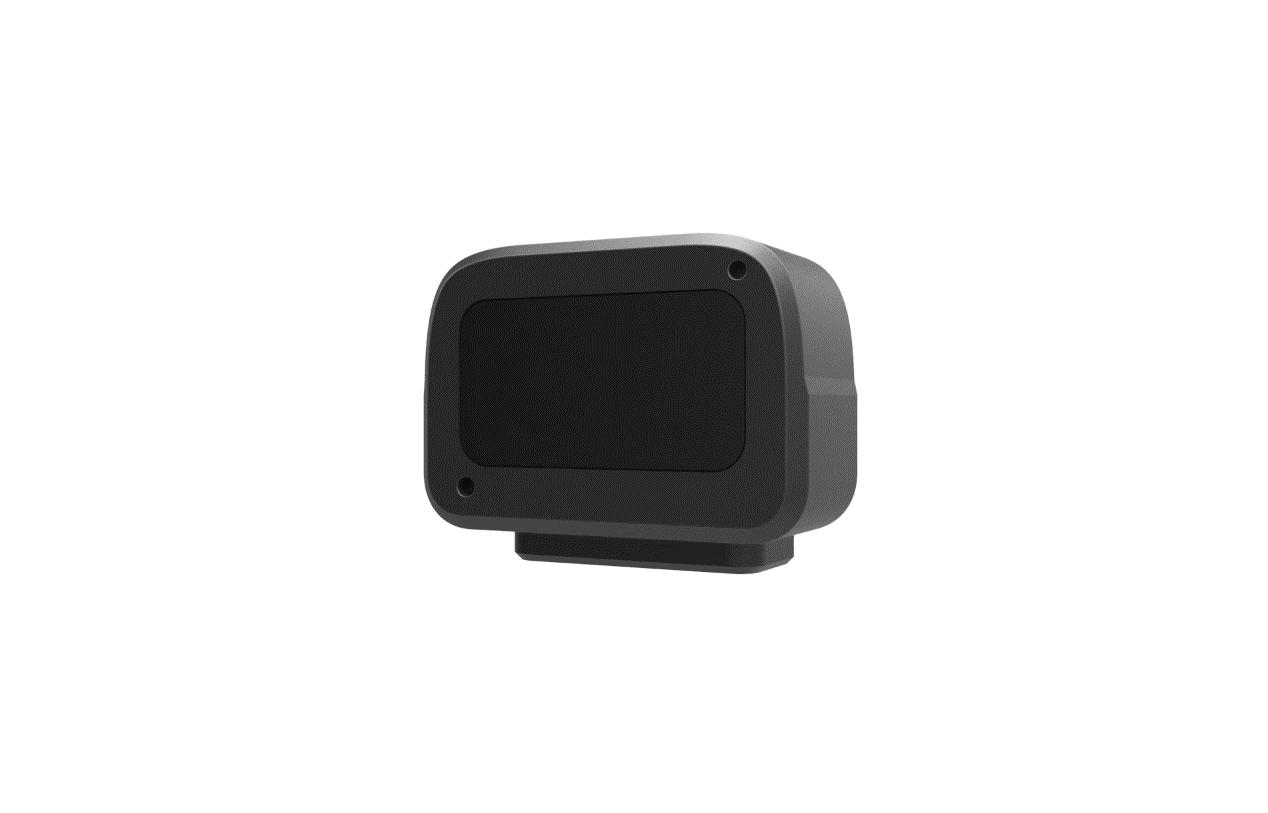
Figure. 2: TF-NOVA Appearance
3.4 FoV The FoV (field of view) is the angle covered by the LiDAR sensor. The vertical FoV is 14° and the horizontal FoV is 1°.
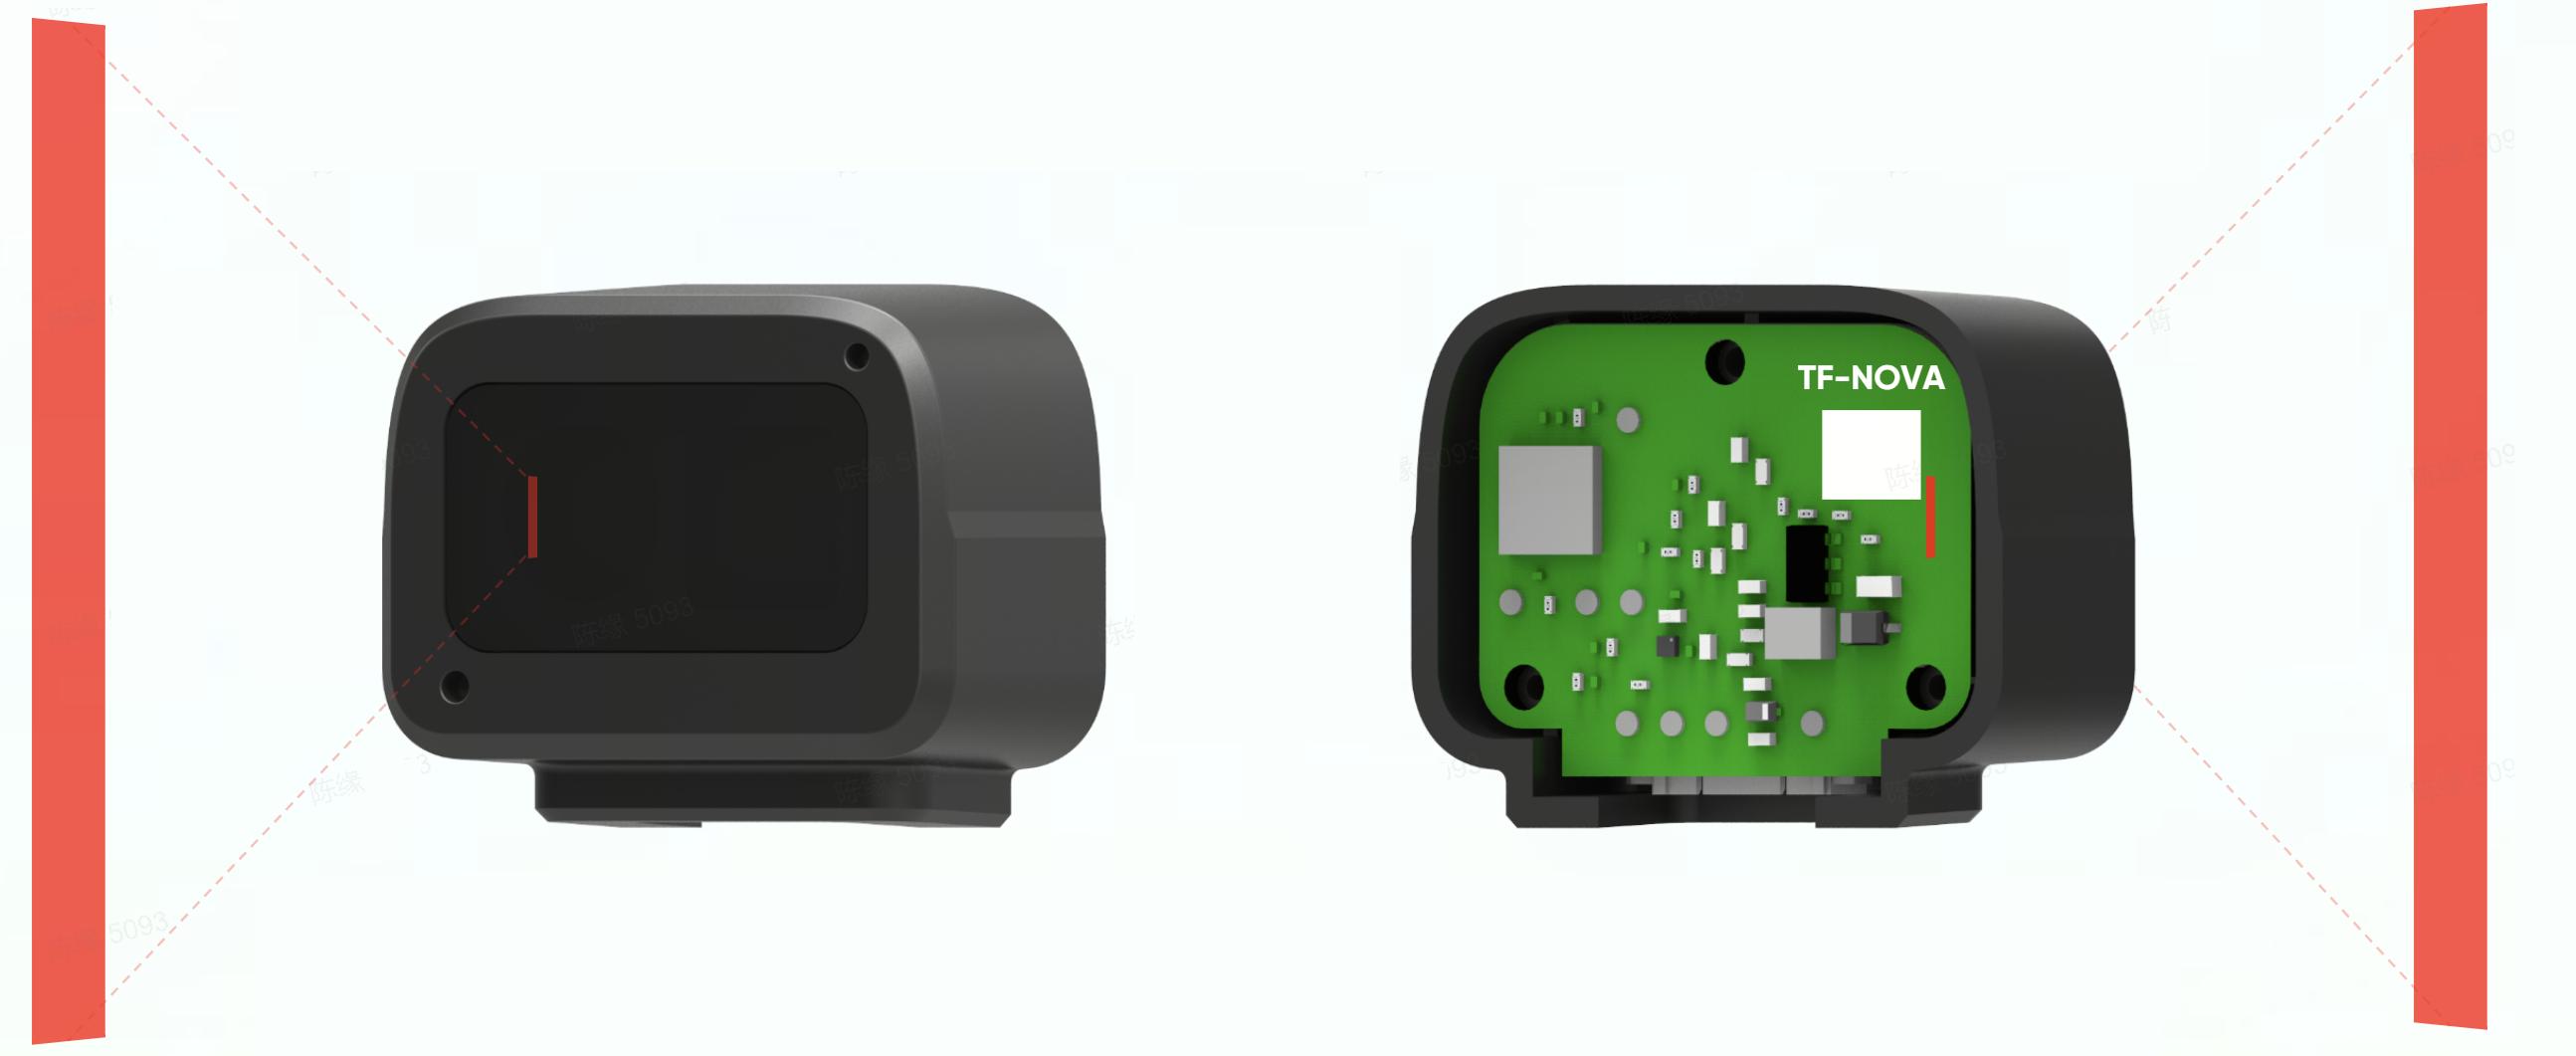
Figure. 3: FoV of TF-NOVA
NOTICE 14° and 1° are theoretic values. Because the manufacturing error and the installing error exist, there is divergence between actual and theoretic values.
4 Device Installation
This section introduces the mechanical installation and connection information of TF-NOVA LiDAR. 4.1 Mechanical Installation As shown in the following figure. TF-NOVA has 2 installation positioning holes available for use.
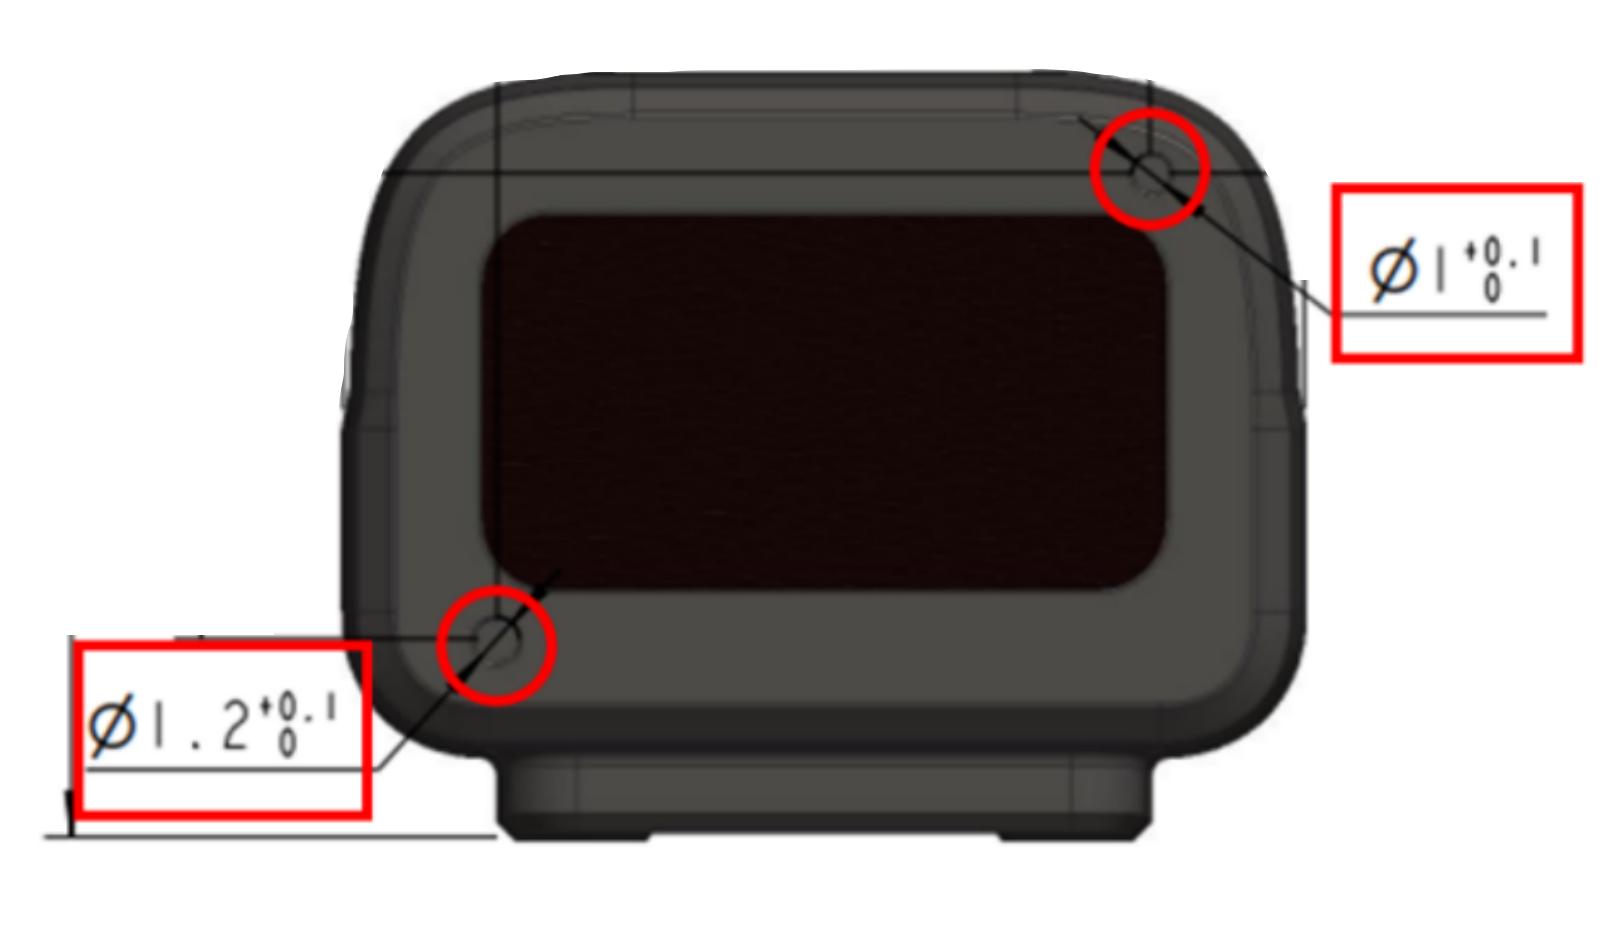
Figure. 4: Diagram of TF-NOVA installation hole
4.2 Connector The connector is 1.25mm-5P, appearance and definition are shown as below:
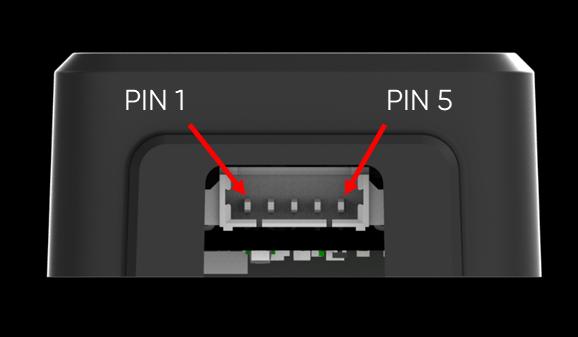
Figure. 5: LiDAR connector appearance
Table. 2: Interface connector pin definitions Pin number Definition
PIN 1 VCC PIN 2 GND PIN 3 TXD(3.3V)/SCL PIN 4 RXD(3.3V)/SDA PIN 5 IO
5 Communication Protocol and Data Format
5.1 Serial Communication To connect two devices for TTL communication, the TXD of the transmitter should be connected to the RXD of the receiver, and the TXD of the receiver should be connected to the RXD of the transmitter. The LiDAR does not include a power switch. When power is supplied to the LiDAR, data will begin to be automatically transmitted.
Table. 3: Characteristics of UART Interface
| Parameter | Value |
|---|---|
| Character | Value Configurability |
| Baud rate | 115200 Configurable |
| Data bit | 8 Non-configurable |
| Stop bit | 1 Non-configurable |
| Parity | None Non-configurable |
NOTE Baud rate can be set to 9600, 14400, 19200, 38400, 56000, 57600, 115200, 128000, 230400, 256000, 460800, 500000, 512000, 600000, 750000, and 921600. If other value were set, TF-NOVA will set it to 115200.
Serial port output format: 9-byte/cm (Default)
Byte 0 1 2 3 4 5 6 7 8 Description 0x59 0x59 Dist_L Dist_H Peak_L Peak_H Temp Confidence Check_sum
Dist: cm Peak: Signal strength Temp: Chip Temperature ℃ Confidence: Confidence level 0-100
9-byte/cm Byte 0 1 2 3 4 5 6 7 8
Description 0x59 0x59 Dist_L Dist_H Peak_L Peak_H Temp Confidence Check_sum
Dist :mm Peak: Signal strength
Temp: Chip Temperature ℃ Confidence: Confidence level 0-100 5.2 IIC Communication TF-NOVA supports up to 400kps clock speed as slave machine and its default address is 0x10. For more information about IIC register table refer to "Appendix IIC REGISTER TABLE".
Note: In this document, the address of IIC slave device is a 7-bit value with value range [0x08, 0x77] ([08, 119] in decimal). For the first byte after IIC releases a start signal, the 7-bit address should be shifted leftward for one bit (i.e. multiplied with 2), and then filled with the read-write sign on the lowest bit. For TF-NOVA, the default address of slave device is 0x10, the address for write operations is 0x20, and the address for read operations is 0x21.
Write register timing: Start Slave Addr W Ack Registe Ack Data1 Ack … DataN Ack Stop
r Addr
Read register timing: Start Slave Addr W Ack Register Addr Ack Stop
Start Slave Addr R Ack Data1 Ack … DataN Nack Stop Note that in the read register sequence, the host can directly generate the second Start signal without generating the first Stop signal. The last Nack can also be an Ack signal. After a write operation on the IIC register, it takes TF-NOVA some time to process. If users need to read the value from the register for validation purposes, we recommend waiting for 100ms after the write operation, prior to the next read operation.
5.3 On/off Mode On/off mode is designed from those users who only need to detect the existence of an object. TF-NOVA can start this mode using “ Enable/disable on-off mode ID_ON_OFF_MODE=0x3B ” and then shows result through pin 5. Figure 5 below
shows how the mode works when a high level is set to represent an object is detected.
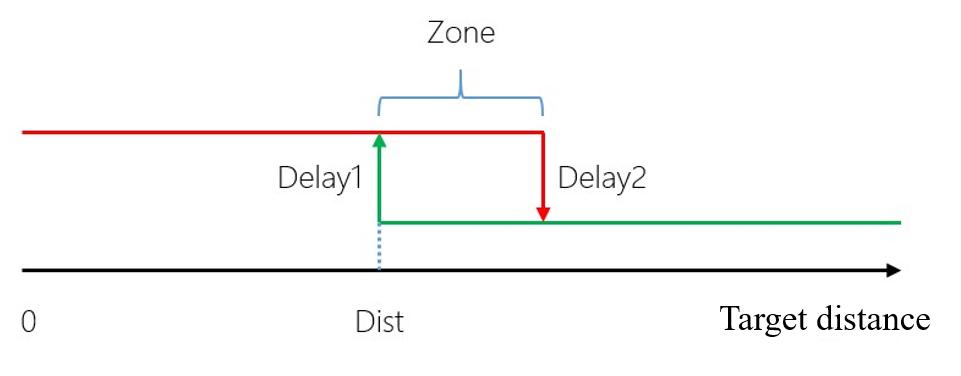
Figure 6 On/off mode that high level means closer
Zone value: If an object is detected closer than Dist, then Pin 5 outputs high-level, but only if an object is detected farther than Dist + Zone, then Pin 5 outputs low- level. When zone is set to 0, pin 5 may output up and down cause by fluctuation of the measuring when the real distance happens to be the same as Dist. That is why a proper zone value is needed to help avoid this situation by having a hysteretic interval. Delay is also supported to avoid inaccurate jumping output. Pin 5 changes its output depends on the Dist value condition and the time it lasts. Delay1 (ms) and Delay2 (ms) determine how long that approaching changes and leaving changes should wait after Dist value is already over the line.
Note: Since the Dist value is set to 0 under factory setting when no object is detected and Amp is too low, then pin 6 may have false output in the on/off mode. 5.4 Serial communication commands Some parameters in TF-NOVA can be customized by customers, such as data frame format, frame rate, etc., which can be changed by sending specific instructions. After successful configuration, all parameters will be saved in Flash and do not need to be reconfigured when powered on again. When configuring parameters, please follow specific formats and rules to avoid sending commends not introduced below.
Byte Definitio Description
n
Byte 0 Head Fixed 0x5A Byte 1 Length The length of bytes from the head byte to check-
sum
| Parameter | Value |
|---|---|
| Byte 2 | ID Indicates how to parse the payload data |
| Byte 3~Byte | Payload Data segment, parsed based on ID, Little Endian |
| N-2 | Opt: Non 1 read/ 1. Write in |
| Byte N-1 | Check The lower 8 bytes of the sum from Head to |
sum Payload
5.4.1 Version information ID_GET_VERSION=0x01 Downward: Byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum Upward: Byte 0 1 2 3-5 Len-1 Description Head(0x5A) Len ID Version Check_sum Version: For instance, if the third, fourth, and fifth bytes are 112, 50, 9, then the version is 9.50.112. Sample: Command [5A 04 01 5F]
5.4.2 System software restore ID_SOFT_RESET=0x02 Downward: Byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum Upward: Byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Status Check_sum Status: 0 (success), otherwise (fail)
Note: Any change without “save current setting” instruction will not be saved and will restore to original setting. Sample: Command [5A 04 02 60]
5.4.3 Output frequency ID_SAMPLE_FREQ=0x03 Downward:
| Parameter | Value |
|---|---|
| Byte | 0 1 2 3~4 Len-1 |
| Description Head(0x5A) | Len ID FPS Check_sum |
| Default | 100 |
Freq: The actual operating frequency achieved by the LiDAR. Upward:
Byte 0 1 2 3~4 Len-1 Description Head(0x5A) Len ID FPS Check_sum
Freq: The actual operating frequency achieved by the LiDAR. Sample: 10Hz [5A 06 03 0A 00 6D]
5.4.4 Output format setting ID_OUTPUT_FORMAT=0x05 Downward:
| Parameter | Value |
|---|---|
| Byte | 0 1 2 3 Len-1 |
| Description Head(0x5A) | Len ID Format Check_sum |
| Default | 0x01 |
Format: 0x01(9byte cm),0x06(9byte mm) Upward:
Byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Format Check_sum
Format: current output format setting Sample: 9byte mm [5A 05 05 06 6A]
5.4.5 Baud rate setting ID_BAUD_RATE=0x06 Downward:
Byte 0 1 2 3~6 Len-1 Description Head(0x5A) Len ID Baudrate Check_sum
Default 115200
Baudrate: current baud rate. Note: Configurable baud rate range [9600 921600], save to take effect after power off. Upward: Byte 0 1 2 3~6 7 Len-1 Description Head(0x5A) Len ID Baudrate Status Check_sum
0: success !0: fail
Sample: 9600 [5A 08 06 80 25 00 00 0D] 19200 [5A 08 06 00 4B 00 00 B3] 38400 [5A 08 06 00 96 00 00 FE] 57600 [5A 08 06 00 E1 00 00 49] 115200 [5A 08 06 00 C2 01 00 2B] 230400 [5A 08 06 00 84 03 00 EF] 460800 [5A 08 06 00 08 07 00 77] 921600 [5A 08 06 00 10 0E 00 86]
5.4.6 Enable/disable output ID_OUTPUT_EN=0x07 Downward:
| Parameter | Value |
|---|---|
| Byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Enable Check_sum |
| Default | 1 |
Enable: 0 (disable),1 (enable). Upward:
Byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Sample: Enable output [5A 05 07 01 67] Disable output [5A 05 07 00 66]
5.4.7 Enable/disable checksum comparison ID_FRAME_CHECKSUM_EN=0x08 Downward:
| Parameter | Value |
|---|---|
| Byte | 0 1 2 3 Len-1 |
| Description | Head(0x5A) Len ID Enable Check_sum |
| Default | 0 |
Enable: 0 (disable), 1 (enable) Note: Even if the Downward data checksum comparison is disabled, the valid checksum is still included in the upward data frame. Upward:
Byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Enable Check_sum
Sample: Enable checksum comparison [5A 05 08 01 68] Disable checksum comparison [5A 05 08 00 67]
5.4.8 Communication interface settings ID_IF_PROTOCOL=0x0A Downward:
| Parameter | Value |
|---|---|
| Byte 0 | 1 2 3 4 Len-1 |
| Description Head(0x5A) | Len ID Opt If_protocol Check_sum |
| Default | !1 |
Opt: !1:read, 1:write If_protocol: !1:UART, 1:IIC Upward: Byte 0 1 2 3 4 Len-1 Description Head(0x5A) Len ID Status If_protocol Check_sum
0: success
!0:fail
Sample: Set to IIC [5A 06 0A 01 01 6C] Note: Effective after saving
5.4.9 IIC slave machine address configuration ID_IIC_SLAVE_ADDR=0x0B Downward:
| Parameter | Value |
|---|---|
| Byte | 0 1 2 3 4 Len-1 |
| Description Head(0x5A) | Len ID Opt IIC_slave_addr Check_sum |
| Default | 0x10 |
Opt: !1: read, 1:write IIC_slave_addr: range[0x08, 0x77] ; Upward: Byte 0 1 2 3 4 Len-1 Description Head(0x5A) Len ID Status IIC_slave_addr Check_sum
0:success
!0:fail
Sample: Set to 0x20 [5A 05 0B 01 20 8B] 5.4.10 Restore default setting ID_RESTORE_DEFAULT=0x10 Downward:
Byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward:
Byte 0 1 2 3 Len-1 Description Head(0x5A) Len ID Status Check_sum
Status: 0(success), Non 0(fail). Sample: Command [5A 04 10 6E]
5.4.11 Save current setting ID_SAVE_SETTINGS=0x11 Downward:
Byte 0 1 2 Len-1 Description Head(0x5A) Len ID Check_sum
Upward:
Byte 0 1 2 3 Len-1
Description Head(0x5A) Len ID Status Check_sum
Status: 0 (success), Non 0 (fail). Sample: Command [5A 04 11 6F]
5.4.12 Distance limit setting range ID_DIST_RANGE=0x3A Downward:
| Parameter | Value |
|---|---|
| Byte 0 | 1 2 3 4-5 6-7 Len-1 |
| Description Head(0x5A) | Len ID Opt Min_dist Max_dist Check_sum |
| Default | 0 65535 |
Opt: !1:read, 1:write Min_dist: minimum distance output in mm Max_dist: maximum distance output in mm Upward: Byte 0 1 2 3 4-5 6-7 Len-1 Description Head(0x5A) Len ID Status Dist_min Dist_max Check_sum Status: 0 (success), Non 0 (fail). Sample: Output limit when out of range with the minimum set to be 200mm and the maximum set to be 5000mm [5A 09 3A 01 C8 00 88 13 01]
5.4.13 Enable/disable on-off mode ID_ON_OFF_MODE=0x3B Downward:
| Parameter | Value |
|---|---|
| Byte 0 | 1 2 3 44 5-6 7-8 9-10 11-12 Len-1 |
| Description Head(0x5A) Len ID Opt Mode Dist Zone Delay1 | Delay2 Check_sum |
| Default | 0 0 0 0 0 |
Opt:!1:read, 1:write Mode: 0 (Normal output), 1 (On-off mode with high level output when closer) , 2 (On-off mode with low level output when closer) Dist: critical dist value (the closer one) in centimeters. Zone: Zone size in centimeters Delay1: Delay time 1 in millisecond. Pin 6 switch level only if the distance detected is less than Dist and the situation last for Delay1 long.
Delay2: Delay time 2 in millisecond. Pin 6 switch level only if the distance detected is more than Dist + Zone and the situation last for Delay2 long. Upward:
Byte 0 1 2 3 44 5-6 7-8 9-10 11-12 Len-1 Description Head(0x5A) Len ID Status Mode Dist Zone Delay1 Delay2 Check_sum
Sample: Enable on-off mode with high level output when closer, and set Dist = 200cm, Zone=10cm, Delay1 = Delay2 = 1000ms: [5A 0E 3B 01 01 C8 00 0A 00 E8 03 E8 03 4D]
CAUTION Do not send the command that is not in the list above.
Appendix IIC REGISTER TABLE
Addres R/ Name Initial Description s W Valu
e
| Parameter | Value |
|---|---|
| 0x00 R DIST_LOW | -- cm |
| 0x01 R DIST_HIGH | -- |
| 0x02 R PEAK_LOW | -- |
| 0x03 R PEAK _HIGH | -- |
| 0x04 R TEMP_LOW | -- Unit: 0.01 Celsius |
| 0x05 R TEMP_HIGH | -- |
| 0x06 R TICK_LOW | -- Timestamp |
| 0x07 R TICK_HIGH | -- |
| 0x08 R ERROR_LOW | -- Error code |
| 0x09 R ERROR_HIGH | -- |
| 0x0A R VERSION_REVISION | -- |
| 0x0B R VERSION_MINOR | -- |
| 0x0C R VERSION_MAJOR | -- |
| 0x0D W/ IIC_SLAVE_IO_SPEED | 0x00 0(2MHz),1(10MHz),2(50MH |
| R | z) |
| 0x10- R SN | -- Production code in 14 |
| 0x1D | byte ASCII code (0x10 is |
the first byte)
0x1E W/ IF_PROTOCOL 0x00 0x00: UART
R 0x01: IIC
Save and restart to take effect
0x20 W SAVE -- Write 0x01 to save
current setting
0x21 W SHUTDOWN/REBOOT -- Write 0x02 to reboot 0x22 W/ SLAVE_ADDR 0x10 range: [0x08, 0x77]
R
| Parameter | Value |
|---|---|
| 0x25 W/ ENABLE | 0x01 0x00: Turn off LiDAR |
| R | 0x01: Turn on LiDAR |
| 0x26 W/ FPS_LOW | 0x64 Frame rate |
R
0x27 W/ FPS_HIGH 0x00
R
| Parameter | Value |
|---|---|
| 0x29 W RESTORE_FACTORY_DEFAULT | -- Write 0x01 to restore |
| S | factory default settings |
| 0x2E W/ MIN_DIST_LOW | 0x00 Minimum dist in mm, but |
| R | not working on |
DUMMY_DIST
0x2F W/ MIN_DIST_HIGH 0x00
R
0x30 W/ MAX_DIST_LOW 0xFF Maximum dist in mm, but
R not working on
DUMMY_DIST
0x31 W/ MAX_DIST_HIGH 0xFF
R
0x32 W/ ON_OFF_MODE_DIST_LOW 0x00 ON_OFF mode related
R registers, please refer to:
ON_OFF mode. Note that the distance unit in the IIC register is mm.
Note: Minimum firmware version V1.3.19
0x33 W/ ON_OFF_MODE_DIST_HIGH 0x00
R
0x34 W/ ON_OFF_MODE_ZONE_LOW 0x00
R
0x35 W/ ON_OFF_MODE_ZONE_HIGH 0x00
R
0x36 W/ ON_OFF_MODE_DELAY1_LOW 0x00
R
0x37 W/ ON_OFF_MODE_DELAY1_HIG 0x00
R H
0x38 W/ ON_OFF_MODE_DELAY2_LO 0x00
R W
0x39 W/ ON_OFF_MODE_DELAY2_HIG 0x00
R H
0x3A W/ ON_OFF_MODE_EN 0x00
R
0x3C- R SIGNATURE -- ‘S’ ’P’ ‘A’ ‘D’ 0x3F